wow.
today was a long, but definitely productive day.
first off, thank you to jessa, emily, doug, and david to devoting their evening and energy.
also, thanks to david for the masssssive box of cookies!
caroline and i first took an... entertaining run to ACE for pvc joints. we now have a rewards card, on the bulletin board in the project room. please do actually use them.
anyway, the joints. we wants to pvc the three-prong claw idea. we'll work on it more tomorrow, but currently, we're limited because the angles of the joints are not exact. also, we really dont know what we would want the angles to be. (or i don't.)
we did some math to figure out what some distances would have to be.
over dinner, emily showed up spiffy solidworks designs of potential arms. wow.
looked at some four-bar linkage stuff, which looks really cool. we still have so many ideas floating around, i think it's definitely time to just sit down and commit to one idea, while still tinkering with a simpler backup. thoughts? our general strategy is so up in the air right now
chassis stuff is getting there, though. i know david was helping anndini & allie with some of that after dinner. mecanum wheels HAVE been ordered. when they'll get here, who knows?
we apparently have some conflicting information about whether you can use skid steer on mecanum wheels. if we can, i think that's definitely something to explore.
in the meantime, doug and emily gave us some awesome programming information about window filtering, and arrays, and global variables, switch debounching, and other cool stuff for having a smoother drivetrain and also just general information. wow. we definitely took the simple way out last year. i don't even know how poor scotty drives.
if we can get the chain on scotty functional, or the prototype chassis up and running, it would definitely be good to start messing with code.
thank you to sallie and ginna for staying through the potentially intimidating programming lecture. definitely ask questions when you're confused.
there are pictures of the notes on picasa.
i feel like i'm missing something critical that we talked about... hmph.
basically the moral of the story is that today was really really productive. it would be more productive if we knew what we wanted our end result to either look like or do. either one. design or general strategy.
things to decide:
-basic direction of chassis. "Fat" vs. narrow
-are we even hurdling to begin with?
-mecanum wheels
--if yes, skid steer or actually sliding!?!
-if we are hurdling, what's the arm/elevator/lift/gripper/whatever? windmill? fourbar?
--how can we get a prototype of a fourbarlinkage going? the solidworks gave us a good idea of roughly how it'll work, but actual details would be good.
-basically everything.
hopefully over this weekend we'll be able to get a lot accomplished. we'll get there. we're getting there.

Wednesday, January 16, 2008
Monday, January 14, 2008
what does em stand for?
...why, extraordinary mentor, of course!
basically, she is amazing. amazingly organized too. when we got to school today, and peeked in the project room.... WOW. i don't even know how to describe it. i have never ever seen it that clean or organized. we know that this shouldn't be a good thing, technically, because, uh, we should be organized. we're not. and thank you thank you thank you! chairs were pushed in. frankly, that just scared us a little. (we did actually mess the chairs up... too much creepy precision)
on a totally different note, can someone with admin priveleges already bump me up to admin too for the build blog (which i'm going to almost solely blog on starting now)
today was one of the few days off. i hope people enjoyed it... i got home at 3:30. wow. thanks to anne and crystal for walking over to ideo. i know they were hoping to get some gear box stuff going.
this week in terms of scheduling:
meeting mon-fri from roughly 4-7:30 (although we may or may not go later depending on mentors and goals for that night.) i know my family's chaperoning and food-ing tuesday and wednesday. let's fill in the schedule on the project room door. if people are good about writing stuff in, its a really useful tool.
mourad (we really need a nickname. dora? raddy? ratty? dorey? mo-rad? suggestions welcome) anyway the point is that she told me she has ordered our mecanum wheels from andymark. i'm totally excited to play around with those and learn how they work!
get ready for a spiffy 37 days left! i'm pumped.
basically, she is amazing. amazingly organized too. when we got to school today, and peeked in the project room.... WOW. i don't even know how to describe it. i have never ever seen it that clean or organized. we know that this shouldn't be a good thing, technically, because, uh, we should be organized. we're not. and thank you thank you thank you! chairs were pushed in. frankly, that just scared us a little. (we did actually mess the chairs up... too much creepy precision)
on a totally different note, can someone with admin priveleges already bump me up to admin too for the build blog (which i'm going to almost solely blog on starting now)
today was one of the few days off. i hope people enjoyed it... i got home at 3:30. wow. thanks to anne and crystal for walking over to ideo. i know they were hoping to get some gear box stuff going.
this week in terms of scheduling:
meeting mon-fri from roughly 4-7:30 (although we may or may not go later depending on mentors and goals for that night.) i know my family's chaperoning and food-ing tuesday and wednesday. let's fill in the schedule on the project room door. if people are good about writing stuff in, its a really useful tool.
mourad (we really need a nickname. dora? raddy? ratty? dorey? mo-rad? suggestions welcome) anyway the point is that she told me she has ordered our mecanum wheels from andymark. i'm totally excited to play around with those and learn how they work!
get ready for a spiffy 37 days left! i'm pumped.
Sunday, January 13, 2008
first week
39 days left!
i've been rather remiss in the blogging for the past couple days.
basically, there's a new design in the works. multiple, actually. i know emily/annie were definitely getting some action with the pvc pipe today. an overpass HAS been constructed. i'm not entirely sure whether it's precise proportions but it looks amaaaaazing. another idea is the three-prong one we've been working with for awhile.
also, are we really going to have an arm? we've all agreed that drive train and strong chassis is definitely the priority. but do we attempt an actuating arm as well?
and for that drive train... mecanum wheels will hopefully be ordered asap, mourad's been given the order. jimmy mentioned that you don't need to program them to slide? you can just use the same old drive code like for anything else? with skid steer? we'll obviously have to check that out.
there are a lot of ideas out there, and while we're beginning to experiment and start doing more serious prototyping, all the leads definitely want a small, focused design meeting with mentors. that's what saturday was planned to be, but it ended up being more general, which is okay. except that as such a young team, we definitely want your opinions and input as well as advice on how to proceed once we finally have a (temporarily) set design we want to aim for.
once again, are we "going fat"? decisions really need to start getting made, but i know we dont want to make those decisions without consulting the mentors as a group rather than individually, where we get conflicting opinions.
oh i just had a random thought: i think that maybe we should just combine the two blog and maybe tag the posts "programming" or "build"? because at least for now, i'm just posting the same thing in two places. and hopefully people are reading both. thoughts? comments?
all the newbies who were around on saturday HAVE been shoptrained (and got to make blocks. grrrr. ) jessa ran a programming 101 workshop, which was definitely useful. so now hopefully sallie, neli, and divya (somewhat) get programming. yay! that's wayyyy farther than programming was last year. i think at the end of the first week, we'd just received "C for dummies" and thought it was a godsend. :)
a temporary electronics board (complete with a battery mount, attached and all!) has been put on the prototype kit chassis. there are also wheels on there. now if only there can be motors. that will happen soon, i believe.
i'm sure there are more things that have happened. actually, i knowww there are more things that have happened. blanking out.
oh! does anyone remember where i put the lugs for the battey leads?! i distinctly remember being like "let's not forget where i'm putting these!" but we've completely forgotten. we need to find those.
thank you (Again!) to doug for providing us with retail therapy. thank you for all the mentors for your commitment and energy and enthusiasm and time. we appreciate it so much.
i'll post random thoughts as they come to me. this is all i have for now.
i've been rather remiss in the blogging for the past couple days.
basically, there's a new design in the works. multiple, actually. i know emily/annie were definitely getting some action with the pvc pipe today. an overpass HAS been constructed. i'm not entirely sure whether it's precise proportions but it looks amaaaaazing. another idea is the three-prong one we've been working with for awhile.
also, are we really going to have an arm? we've all agreed that drive train and strong chassis is definitely the priority. but do we attempt an actuating arm as well?
and for that drive train... mecanum wheels will hopefully be ordered asap, mourad's been given the order. jimmy mentioned that you don't need to program them to slide? you can just use the same old drive code like for anything else? with skid steer? we'll obviously have to check that out.
there are a lot of ideas out there, and while we're beginning to experiment and start doing more serious prototyping, all the leads definitely want a small, focused design meeting with mentors. that's what saturday was planned to be, but it ended up being more general, which is okay. except that as such a young team, we definitely want your opinions and input as well as advice on how to proceed once we finally have a (temporarily) set design we want to aim for.
once again, are we "going fat"? decisions really need to start getting made, but i know we dont want to make those decisions without consulting the mentors as a group rather than individually, where we get conflicting opinions.
oh i just had a random thought: i think that maybe we should just combine the two blog and maybe tag the posts "programming" or "build"? because at least for now, i'm just posting the same thing in two places. and hopefully people are reading both. thoughts? comments?
all the newbies who were around on saturday HAVE been shoptrained (and got to make blocks. grrrr. ) jessa ran a programming 101 workshop, which was definitely useful. so now hopefully sallie, neli, and divya (somewhat) get programming. yay! that's wayyyy farther than programming was last year. i think at the end of the first week, we'd just received "C for dummies" and thought it was a godsend. :)
a temporary electronics board (complete with a battery mount, attached and all!) has been put on the prototype kit chassis. there are also wheels on there. now if only there can be motors. that will happen soon, i believe.
i'm sure there are more things that have happened. actually, i knowww there are more things that have happened. blanking out.
oh! does anyone remember where i put the lugs for the battey leads?! i distinctly remember being like "let's not forget where i'm putting these!" but we've completely forgotten. we need to find those.
thank you (Again!) to doug for providing us with retail therapy. thank you for all the mentors for your commitment and energy and enthusiasm and time. we appreciate it so much.
i'll post random thoughts as they come to me. this is all i have for now.
Tuesday, January 08, 2008
monday and tuesday
i think for now the same postings will go on both blogs... we're not really doing anything separately
sorry for no post yesterday, and today will have to be quick
summary version: we have a basic arm idea. maybe i can get a picture in here somehow?
trying to finalize motors/potentiometers and how to mount, etc.
drive train: 6 wheels? or 4? definitely steering the front two. any input on how cars works would be greatly appreciated.
there has been some math-doing. :) but i assume there is more to come.
thank you thank you to karlin and tiffany for coming
and i believe there are cart designs in the works
a question: are we ACTUALLY going to use sketchup/solidworks? i think we should... if we know how.
we should start making BoMs and weight lists
that's all
sorry for no post yesterday, and today will have to be quick
summary version: we have a basic arm idea. maybe i can get a picture in here somehow?
trying to finalize motors/potentiometers and how to mount, etc.
drive train: 6 wheels? or 4? definitely steering the front two. any input on how cars works would be greatly appreciated.
there has been some math-doing. :) but i assume there is more to come.
thank you thank you to karlin and tiffany for coming
and i believe there are cart designs in the works
a question: are we ACTUALLY going to use sketchup/solidworks? i think we should... if we know how.
we should start making BoMs and weight lists
that's all
Sunday, January 06, 2008
we've kicked off!
hello!
the 2008 season has begun! build and programming are working together on the design process, so i've posted this to both blogs.
caroline, me, allie, and nandini headed down at the crack of dawn (literally...) saturday to recieve the challenge from sj state. this year's challenge, first overdrive, is different from any other challenge. effectively, it's a racetrack with oversized inflatable balls. these are the game pieces. it's really hard to describe - search for first overdrive 08 on youtube and you should find something. i think this should link to it: http://youtube.com/watch?v=GKBIEqY2Ak4
we had a great turnout for brainstorming session at school saturday. many mentors came, and thank you for that. we broke into groups and came up with many rough ideas.
then, today, with a smaller turnout (allie, caroline, anndini, annie c, sallie, crystal, mari, neli, me...) we presented our design ideas and began to PROTOTYPE! the two main arm concepts at this point are the shoulder-elbow-wrist extendable design, as recommended by jimmy and a forklift. very rough prototyping with 80/20 ensued. allie and i also put together the kit chassis as a prototype.
things to think about:
what is going to grip that thing? the ball is huge, and fairly slippery.
what is our overall strategy? i know we're hoping to go over rather than under the overpass, but are we going to place it on top at the end?
what's our priority?
hybrid?
sensors?
we've been discussing many different concepts for a drive train. obviously, scotty's will not work. we can't almost tip over every time we turn...
possibilities:
-mecanum wheels. like jester drive (is it possible to buy them? how difficult is the programming?)
-omni wheels (again. expensive. no experience with them)
-omni wheel/traction wheel combo. we saw a lot of this in atlanta
-power steering two smaller front wheel
-combination of casters and driven wheels
-anything i've forgotten
this is something we'll have to continue to think about.
oh, there's a schedule of deadlines on the project room whiteboard. that will come soon. we deffffinitely need to be testing far earlier this year, and spend less time on prototyping. i know we're hoping to have parents help out to build an overpass, and we want to make good use of that.
uh, also, can we get that leak in the closet taken care of? ...it makes me nervous.
a HUGE THANK YOU to doug for generally being an amazing source of information as well as providing the books and tools necessary. those hex screwdrivers will make everything so much easier. :D
also thanks to karlin for coming in to help us talk through concepts, and marsha abbott for chaperoning and yummy dips for the pita, as well as the costco run.
get ready for season! i'm excited. hopefully you are too. :)
the 2008 season has begun! build and programming are working together on the design process, so i've posted this to both blogs.
caroline, me, allie, and nandini headed down at the crack of dawn (literally...) saturday to recieve the challenge from sj state. this year's challenge, first overdrive, is different from any other challenge. effectively, it's a racetrack with oversized inflatable balls. these are the game pieces. it's really hard to describe - search for first overdrive 08 on youtube and you should find something. i think this should link to it: http://youtube.com/watch?v=GKBIEqY2Ak4
we had a great turnout for brainstorming session at school saturday. many mentors came, and thank you for that. we broke into groups and came up with many rough ideas.
then, today, with a smaller turnout (allie, caroline, anndini, annie c, sallie, crystal, mari, neli, me...) we presented our design ideas and began to PROTOTYPE! the two main arm concepts at this point are the shoulder-elbow-wrist extendable design, as recommended by jimmy and a forklift. very rough prototyping with 80/20 ensued. allie and i also put together the kit chassis as a prototype.
things to think about:
what is going to grip that thing? the ball is huge, and fairly slippery.
what is our overall strategy? i know we're hoping to go over rather than under the overpass, but are we going to place it on top at the end?
what's our priority?
hybrid?
sensors?
we've been discussing many different concepts for a drive train. obviously, scotty's will not work. we can't almost tip over every time we turn...
possibilities:
-mecanum wheels. like jester drive (is it possible to buy them? how difficult is the programming?)
-omni wheels (again. expensive. no experience with them)
-omni wheel/traction wheel combo. we saw a lot of this in atlanta
-power steering two smaller front wheel
-combination of casters and driven wheels
-anything i've forgotten
this is something we'll have to continue to think about.
oh, there's a schedule of deadlines on the project room whiteboard. that will come soon. we deffffinitely need to be testing far earlier this year, and spend less time on prototyping. i know we're hoping to have parents help out to build an overpass, and we want to make good use of that.
uh, also, can we get that leak in the closet taken care of? ...it makes me nervous.
a HUGE THANK YOU to doug for generally being an amazing source of information as well as providing the books and tools necessary. those hex screwdrivers will make everything so much easier. :D
also thanks to karlin for coming in to help us talk through concepts, and marsha abbott for chaperoning and yummy dips for the pita, as well as the costco run.
get ready for season! i'm excited. hopefully you are too. :)
Tuesday, February 20, 2007
Our nameless robot has been shipped!!!
Around 5:00 today, as we were wrapping plastic around the outside of our awesome crate, FedEx arrived to collect our robot! Enjoy your day off tomorrow, and get excited for packing stuff for portland on Thursday...
THINGS WE HAVE TO PACK FOR PORTLAND (in addition to tools, etc.)
-the radio for the robot that we accidentally forgot to pack into the crate after taking it off the
-chain tensioning delrin rod system
-grip tape
-emergency ramp kit: rivets, punch (for holes in surgical tubing), surgical tubing (about 3/8" outer diameter, 1/8" ID), box cutters, drill bit (in rivets bag), back-up plates (washers for pop rivets), cable and crimps...
-slides for bottom or ramp supports
-extra signs with school name, sponser, etc. (already printed)
-and more...think about what we need!
other:
-strategy
-figure out what to do about indicator light for which we're missing the relay...
good night--go catch up on all that lost sleep!
THINGS WE HAVE TO PACK FOR PORTLAND (in addition to tools, etc.)
-the radio for the robot that we accidentally forgot to pack into the crate after taking it off the
-chain tensioning delrin rod system
-grip tape
-emergency ramp kit: rivets, punch (for holes in surgical tubing), surgical tubing (about 3/8" outer diameter, 1/8" ID), box cutters, drill bit (in rivets bag), back-up plates (washers for pop rivets), cable and crimps...
-slides for bottom or ramp supports
-extra signs with school name, sponser, etc. (already printed)
-and more...think about what we need!
other:
-strategy
-figure out what to do about indicator light for which we're missing the relay...
good night--go catch up on all that lost sleep!
Monday, February 19, 2007
We're 121 lbs!!!...
...with a 12V battery.
After a moment of freaking out about needing to lose 11 lbs, we realized we hadn't removed the battery. The arm wasn't on the robot, however, so as far as we can tell, we're right at 110 lbs. At least we don't have to go through the extreme weight loss program as last year!
Oh yeah, did I mention we have sweet ramps that get released by a nifty flipper?! Ok, so maybe I shouldn't be so excited given we're shipping in less than 48 hrs, but I have to say I feel a lot less stressed than last year or the year before. We also have a gripper that's done, save maybe a few simple improvements tomorrow as we test.
I took some detail photos of the robot tonight, so if any of you readers want to build a copy of our robot...the pictures say it all, so I'll end my post with short list of things we might consider doing before we ship (should we have the time, that is, in some cases):
-color code for different allen key sizes
-spray paint 1700 on bumpers
-signage (sponsers,
-cart (at least get dimensions so we can do after ship, if it comes to that)
-stuff i can't remember because it's too late and my memory is going...
other:
-strategy
After a moment of freaking out about needing to lose 11 lbs, we realized we hadn't removed the battery. The arm wasn't on the robot, however, so as far as we can tell, we're right at 110 lbs. At least we don't have to go through the extreme weight loss program as last year!
Oh yeah, did I mention we have sweet ramps that get released by a nifty flipper?! Ok, so maybe I shouldn't be so excited given we're shipping in less than 48 hrs, but I have to say I feel a lot less stressed than last year or the year before. We also have a gripper that's done, save maybe a few simple improvements tomorrow as we test.
I took some detail photos of the robot tonight, so if any of you readers want to build a copy of our robot...the pictures say it all, so I'll end my post with short list of things we might consider doing before we ship (should we have the time, that is, in some cases):
-color code for different allen key sizes
-spray paint 1700 on bumpers
-signage (sponsers,
-cart (at least get dimensions so we can do after ship, if it comes to that)
-stuff i can't remember because it's too late and my memory is going...
other:
-strategy
Sunday, February 18, 2007
2 days left (plus a little...)
ACK!
And (surprise surprise) weight is an issue, though not as bad as last year. We're at about 107 lb without the ramp release mechanism or dampers or a few smaller things. Hmmm...
Ramps are almost done, meaning they're dampened, hinged, and supported; they just need some stronger springs. We made do with bungee cords tonight (to open up the secondary ramp), and it was pretty sweet. We did note the problem of getting the cable (connected to the ramp frame and the ramp support) caught around the ramp support...
A gripper idea in the works (suction-y), and we have a working design already.
To do:
ramp release mechanism
wheels/slides/whatever for end of ramp
finish putting grip tape on second ramp
cross-bracing for tower
(test ramps with paly?)
drill last mounting holes for bumpers
See pictures ;)
And (surprise surprise) weight is an issue, though not as bad as last year. We're at about 107 lb without the ramp release mechanism or dampers or a few smaller things. Hmmm...
Ramps are almost done, meaning they're dampened, hinged, and supported; they just need some stronger springs. We made do with bungee cords tonight (to open up the secondary ramp), and it was pretty sweet. We did note the problem of getting the cable (connected to the ramp frame and the ramp support) caught around the ramp support...
A gripper idea in the works (suction-y), and we have a working design already.
To do:
ramp release mechanism
wheels/slides/whatever for end of ramp
finish putting grip tape on second ramp
cross-bracing for tower
(test ramps with paly?)
drill last mounting holes for bumpers
See pictures ;)
Thursday, February 15, 2007
We're getting there
Somehow Jim and being at IDEO make everything work out. We're now done with the secondary ramps and have mounted a main ramp on hinges connected to the chassis (and removed it, so electronics could flip the chassis and drill a couple holes). Our next plan for action is to figure out how to mount the vertical ramp supports and the dampers on the ramps. I think we're sticking to the cable idea for aligning the supports. We also have somewhat of an idea to mount the dampers (we did all of this on our prototype!), but this needs some reworking because the top back chassis rail isn't one piece straight acros the width of the frame. Rather, there's a gap in the middle, leaving no room to mount a damper.
The gap is, however, a perfect fit (as it was intended to be) for the new gripper design that is similar to our previous design, except it has two prongs spaced >10" (the diameter of the spider arm circular plate). We need to finalize this tomorrow and fabricate it, too...and test it on THE RACK! Once this design is set, we also need to add cross bracing to the tower at heights that're appropriate for mounting touch sensors (to prevent the arm from rotating too much in either direction).
The battery mount is also in progress and will hopefully be done by the end of tomorrow.
On top of all the stuff already listed above, PLEASE READ THE LAST FEW BLOGS FOR OTHER THINGS THAT STILL NEED TO BE DONE.
[OI board? (currently we're using last year's--is this even legal?)
bumpers, signage, flag holder, etc.
crate! contact mr. reichling... (Kersten?)]
Little stuff that I don't want to be doing the night before/the day of ship...
A big thanks to Jim for staying with Chrissy and me these past few days until AFTER 10:00!!
The gap is, however, a perfect fit (as it was intended to be) for the new gripper design that is similar to our previous design, except it has two prongs spaced >10" (the diameter of the spider arm circular plate). We need to finalize this tomorrow and fabricate it, too...and test it on THE RACK! Once this design is set, we also need to add cross bracing to the tower at heights that're appropriate for mounting touch sensors (to prevent the arm from rotating too much in either direction).
The battery mount is also in progress and will hopefully be done by the end of tomorrow.
On top of all the stuff already listed above, PLEASE READ THE LAST FEW BLOGS FOR OTHER THINGS THAT STILL NEED TO BE DONE.
[OI board? (currently we're using last year's--is this even legal?)
bumpers, signage, flag holder, etc.
crate! contact mr. reichling... (Kersten?)]
Little stuff that I don't want to be doing the night before/the day of ship...
A big thanks to Jim for staying with Chrissy and me these past few days until AFTER 10:00!!
Tuesday, February 13, 2007
Ramps (cont.)
We're almost done with mounting the surfaces on one whole ramp (the main ramp is done, and we need to mount one more aluminum sheet, which has already been punched out, on the secondary ramp). Once that is done, we can work out how to mount the two pieces together, incorporate the support, and mount it all onto the chassis.
Along with the list of stuff in my previous blog, these things also have to get done:
Ramp release mechanism--I think we're at a point where we should be able to have it all ready to mount on the tower of power. Let's try to get that done within the next two days.
Gripper redesign--it turns out the design we've been planning to use doesn't work. Chrissy and I stayed really late trying to work something out, but this needs more thought.
We're going to IDEO tomorrow and getting there AT FIVE-THIRTY (5:30!!!! NO LATER PLEASE!!!). Maybe you've noticed we've been getting there a half hour late every time, which is bad because we HAVE TONS TO DO (and we're wasting Jim's time if we're not there)!!!
When we go, we need to take:
-The chassis and arm (if programming is ok with this...if not, maybe they can follow)
-A battery (so we can weld a mount onto the chassis)
-Notebooks
-That bag with safety glasses and that 1.5' piece of pvc
-and probably other stuff, too...
Along with the list of stuff in my previous blog, these things also have to get done:
Ramp release mechanism--I think we're at a point where we should be able to have it all ready to mount on the tower of power. Let's try to get that done within the next two days.
Gripper redesign--it turns out the design we've been planning to use doesn't work. Chrissy and I stayed really late trying to work something out, but this needs more thought.
We're going to IDEO tomorrow and getting there AT FIVE-THIRTY (5:30!!!! NO LATER PLEASE!!!). Maybe you've noticed we've been getting there a half hour late every time, which is bad because we HAVE TONS TO DO (and we're wasting Jim's time if we're not there)!!!
When we go, we need to take:
-The chassis and arm (if programming is ok with this...if not, maybe they can follow)
-A battery (so we can weld a mount onto the chassis)
-Notebooks
-That bag with safety glasses and that 1.5' piece of pvc
-and probably other stuff, too...
Ramping it up...
oh dang. i just lost my post because my internet hung. here's a quick version of it.
main ramps = DONE!
secondary ramps = started! aluminum sheet surface cut to correct size and shape.
to do tomorrow (sounds like lots to easy stuff-but will take time!!! only a week left!!):
-draw grid on ramp material and mark points with the punch (borrowed from ideo. don't lose it)
-arm: determine desired length and angle of gripper
-bumpers
-signage--read the rules
-pvc flag holder
-joystick board--place to put joysticks, oi...
-think about hinges/dampers for ramps
other stuff:
-crate? kersten, are you in touch with mr. reichling? HOW IS THE ROBOT GETTING SECURED INSIDE?
-electronics cover
-battery mount (orientation? placement?)
-cross bracing on tower of power
other other:
-chairman's?
main ramps = DONE!
secondary ramps = started! aluminum sheet surface cut to correct size and shape.
to do tomorrow (sounds like lots to easy stuff-but will take time!!! only a week left!!):
-draw grid on ramp material and mark points with the punch (borrowed from ideo. don't lose it)
-arm: determine desired length and angle of gripper
-bumpers
-signage--read the rules
-pvc flag holder
-joystick board--place to put joysticks, oi...
-think about hinges/dampers for ramps
other stuff:
-crate? kersten, are you in touch with mr. reichling? HOW IS THE ROBOT GETTING SECURED INSIDE?
-electronics cover
-battery mount (orientation? placement?)
-cross bracing on tower of power
other other:
-chairman's?
Sunday, February 11, 2007
Sunday, Jan 7
A lot of punching went on today.
First, we all arrived at Castilleja and worked on some stuff (like moving tables, sending emails, and making bumpers) and then Monta Vista arrived to use the rack and then Allie and Anne worked on the crate and Jimmy woke up so we went to IDEO, but not before Bud dropped by and we all had a chat, which was great because Bud is awesome. And then he came to IDEO with us and stuck around for a while, and then programming came to IDEO, so there was a big programming/electronics and ramp design party in the shop, and we punched a lot of stuff and the upshot of all of that is that we have a main ramp that holds more than we need it to and that weighs 7.4 lbs! YES!
Weight check:
-4 ramp frames = 15 lbs
-chassis and arm and tower = 65 lbs
-electronics board = really light because thy remounted stuff on a sort of corrugated plastic sheet.
Also, we need an optical potentiometer.
Also also we need to put together (that is, clamp, drill, rivet, punch) the rest of the ramps, and then we need to support them, and then do hinges, and then dampers. So keep cracking, guys! Keep up the good work for the next 9 days (AAAAAAAHHHHHHHHHHHHHHHHHHHHHHHHHHHHHHHHHHHHHHHH!!!!!!!!!!!!!!!!!!)
First, we all arrived at Castilleja and worked on some stuff (like moving tables, sending emails, and making bumpers) and then Monta Vista arrived to use the rack and then Allie and Anne worked on the crate and Jimmy woke up so we went to IDEO, but not before Bud dropped by and we all had a chat, which was great because Bud is awesome. And then he came to IDEO with us and stuck around for a while, and then programming came to IDEO, so there was a big programming/electronics and ramp design party in the shop, and we punched a lot of stuff and the upshot of all of that is that we have a main ramp that holds more than we need it to and that weighs 7.4 lbs! YES!
Weight check:
-4 ramp frames = 15 lbs
-chassis and arm and tower = 65 lbs
-electronics board = really light because thy remounted stuff on a sort of corrugated plastic sheet.
Also, we need an optical potentiometer.
Also also we need to put together (that is, clamp, drill, rivet, punch) the rest of the ramps, and then we need to support them, and then do hinges, and then dampers. So keep cracking, guys! Keep up the good work for the next 9 days (AAAAAAAHHHHHHHHHHHHHHHHHHHHHHHHHHHHHHHHHHHHHHHH!!!!!!!!!!!!!!!!!!)
Tuesday, February 06, 2007
monday
Today we wrote letters for a while (which are due TODAY, btw) and then, once we figured out our transportation, headed over to IDEO. Jim has machined us some wonderful stuff, like transmission mounts and the motor mount for Chrissy's arm. We also had him drill holes in the new chassis and we can put wheels and (almost) transmissions on the actual robot. We still don't know what ramp material we're going to use. We still (consequently) don't know whether we'll use a flipper (Free Willy) or some latch and cable device to keep the ramps in (does anyone else think that latches and cables might be a bit iffy if we get run into?). We still might end up buying the Andymark transmissions. We need to go to Alan Steel to buy some stuff (there's a list somewhere... Julia?). If anyone knows anything about where to buy structural bamboo, post a comment here or talk to me or Julia or Chrissy about it.
Thanks to Ms Doerr for the sushi.
Good work on the crate, freshman.
Thanks to Ms Doerr for the sushi.
Good work on the crate, freshman.
Saturday, February 03, 2007
Saturday
Today we:
-worked on the crate with our wonderful parent volunteer, Mr Reichling. It's now at the painting stage, and we should be finished very soon (which is good, because the robot needs to ship very soon).
-worked on the whole ramp system
-sent Kersten to Ace and IDEO for hinges, allen keys, and advice
-skyped emily
-ate lunch
-drank tea
-made a mess/ work in progress
-cleaned it up
-tested the now complete (if somewhat flawed in the hinge and damper category) ramp system to see that it (mostly) WORKS! So that was cool. It looks like all our effort to design it has worked out.
So now we need to:
-see what sort of surface we want on these ramps
-see if we want to change the ramp release mechanism (cable and latches?)
-go to allen steel for possible ramp material and the aluminum axle rod for the arm
-figure out what we're going to do about our transmissions. The options are to buy the Andy mark ones, use last years' (which may not be legal, so we need to see what the rule book says about that), see what the authorities are going to do about the ones from this year, or ask Jim if maybe he can help us modify them
-go to IDEO monday at 5:30 to talk stuff over with Jim
-WRITE OUR LETTERS
-build the robot and win regionals and nationals
so get to work, everybody! (and if that isn't motivation enough, talk to Julia and see what phrase she uses)
-worked on the crate with our wonderful parent volunteer, Mr Reichling. It's now at the painting stage, and we should be finished very soon (which is good, because the robot needs to ship very soon).
-worked on the whole ramp system
-sent Kersten to Ace and IDEO for hinges, allen keys, and advice
-skyped emily
-ate lunch
-drank tea
-made a mess/ work in progress
-cleaned it up
-tested the now complete (if somewhat flawed in the hinge and damper category) ramp system to see that it (mostly) WORKS! So that was cool. It looks like all our effort to design it has worked out.
So now we need to:
-see what sort of surface we want on these ramps
-see if we want to change the ramp release mechanism (cable and latches?)
-go to allen steel for possible ramp material and the aluminum axle rod for the arm
-figure out what we're going to do about our transmissions. The options are to buy the Andy mark ones, use last years' (which may not be legal, so we need to see what the rule book says about that), see what the authorities are going to do about the ones from this year, or ask Jim if maybe he can help us modify them
-go to IDEO monday at 5:30 to talk stuff over with Jim
-WRITE OUR LETTERS
-build the robot and win regionals and nationals
so get to work, everybody! (and if that isn't motivation enough, talk to Julia and see what phrase she uses)
Mostly ramps
The coil springs definitely seem to be working at the joint b/w main and secondary on our 80-20 ramp! (note: depending on the final surface material for our ramp, mounting them may be a little more challenging, but doable, of course).
The dampers are also showing promise; we used some L-brackets to mount them onto our 80-20 chassis and ramp and slowed down the 20 lb ramp significantly (not necessarily enough, but the real ramp won't be 20 lb...). Unfortunately, even with a less significant crash into the floor, the end piece on one of the dampers (with a ball and socket joint) broke. It's still usuable, but this is a problem we have to address.
The mesh seems to be strong enough to hold a robot, provided there is no hole cut out for the ramp release mechanism. If we go with the mesh (possibly two layers of it?), we'll have to:
1) rework the release mechanism (not completely, but I don't think what we currently have will work since it requires a hole...)
2) consider the sag-factor: will the robot stay above 12"? will sag prevent robots from being able to climb up the secondary ramp and onto the main part of the ramp?
To Do:
•Sat Morning--PLACE A MCMASTER ORDER SO IT'LL ARRIVE MONDAY
•plot out location of transmissions and electronics board (keeping in mind the arm has to fit "inside the chassis" at the beginning of each round, before it flips "open" to be in front of the robot)
•consider whether our arm/gripper is going to work with/fit over the black flexible-ish tube on the spider arms
•calc exact distance on either side of robot in home zone when ramps are deployed, and possibly get a max secondary ramp length based on this number
•continue work on ramps: SUPPORTS (either buy hinges from mcmaster or pick some up from ACE; make supports from wood?; cable...possibly buy for crimps for when we need them eventually)
•buy more transmission sprockets if we decided to run two loops of chain from each transmission (one to the middle wheel, and one to the back wheel). (but we don't need any more chain! just possibly some master and half links)
•SKYPE EM AT THREE!
•Mr. Reichling will be here to help construct crate! maybe paint it, too....
see ya! (and don't forget your HOMEWORK :D )
The dampers are also showing promise; we used some L-brackets to mount them onto our 80-20 chassis and ramp and slowed down the 20 lb ramp significantly (not necessarily enough, but the real ramp won't be 20 lb...). Unfortunately, even with a less significant crash into the floor, the end piece on one of the dampers (with a ball and socket joint) broke. It's still usuable, but this is a problem we have to address.
The mesh seems to be strong enough to hold a robot, provided there is no hole cut out for the ramp release mechanism. If we go with the mesh (possibly two layers of it?), we'll have to:
1) rework the release mechanism (not completely, but I don't think what we currently have will work since it requires a hole...)
2) consider the sag-factor: will the robot stay above 12"? will sag prevent robots from being able to climb up the secondary ramp and onto the main part of the ramp?
To Do:
•Sat Morning--PLACE A MCMASTER ORDER SO IT'LL ARRIVE MONDAY
•plot out location of transmissions and electronics board (keeping in mind the arm has to fit "inside the chassis" at the beginning of each round, before it flips "open" to be in front of the robot)
•consider whether our arm/gripper is going to work with/fit over the black flexible-ish tube on the spider arms
•calc exact distance on either side of robot in home zone when ramps are deployed, and possibly get a max secondary ramp length based on this number
•continue work on ramps: SUPPORTS (either buy hinges from mcmaster or pick some up from ACE; make supports from wood?; cable...possibly buy for crimps for when we need them eventually)
•buy more transmission sprockets if we decided to run two loops of chain from each transmission (one to the middle wheel, and one to the back wheel). (but we don't need any more chain! just possibly some master and half links)
•SKYPE EM AT THREE!
•Mr. Reichling will be here to help construct crate! maybe paint it, too....
see ya! (and don't forget your HOMEWORK :D )
Friday, February 02, 2007
JIm is a welding master
Duh. Ok, we all knew that. Still, he continues to amaze me! Tonight he welded the main platform for one of the ramps. In addition, he welded the two sides of our tower of power, complete with homemade L-brackets that will allow us to adjust the placement of the tower on our chassis. Our real robot is still looking pretty skeleton-like, but it's beginning to take form!!!
In other news, we got our 72 tooth sprocket today. Some funky stuff going on with a couple of teeth, but according to Jim, "the chain doesn't care," so we're ready to proceed on that front. Some folks also worked on prototyping with wire mesh on the ramp. Jim has also suggested a thin sheet of aluminum (for Kersten, preferably one that makes cool sounds).
To buy (this is also in my notebook, which isn't with me, so I may be forgetting something):
ALUMINUM ROD (to replace the steel one we're currently using for arm)-3/4" diameter, I have a part number (mcmaster)
Hinges for Ramp--Kersten and I started working on this, considering what kind we want at each joint on the ramps ("leaves lay flat" hinges, etc.)
Two 1/2" shaft collars (I think we may have some of these, so let's check first)
To find out:
-Do our current coil springs on ramp work without a pin in the spring hinges at that joint (in other words, would the coil springs with springless hinges provide sufficient ramp-unfolding action)?
-What's our status on weight? (the main platform of a ramp that Jim welded for us is 3.8 lb, so we're already at a total of about 40 lb for the welded frames of both ramps, the tower of power w/o the arm, and the chassis frame).
Lastly, DO YOUR ROBOTICS HOMEWORK!!!! IT'S *REALLY* IMPORTANT. We need a letter from EVERY one of you!
Here is the link to the specifics of the assignment, again, just in case:
http://www.usfirst.org/community/frc/content.aspx?id=4066
thanks!
In other news, we got our 72 tooth sprocket today. Some funky stuff going on with a couple of teeth, but according to Jim, "the chain doesn't care," so we're ready to proceed on that front. Some folks also worked on prototyping with wire mesh on the ramp. Jim has also suggested a thin sheet of aluminum (for Kersten, preferably one that makes cool sounds).
To buy (this is also in my notebook, which isn't with me, so I may be forgetting something):
ALUMINUM ROD (to replace the steel one we're currently using for arm)-3/4" diameter, I have a part number (mcmaster)
Hinges for Ramp--Kersten and I started working on this, considering what kind we want at each joint on the ramps ("leaves lay flat" hinges, etc.)
Two 1/2" shaft collars (I think we may have some of these, so let's check first)
To find out:
-Do our current coil springs on ramp work without a pin in the spring hinges at that joint (in other words, would the coil springs with springless hinges provide sufficient ramp-unfolding action)?
-What's our status on weight? (the main platform of a ramp that Jim welded for us is 3.8 lb, so we're already at a total of about 40 lb for the welded frames of both ramps, the tower of power w/o the arm, and the chassis frame).
Lastly, DO YOUR ROBOTICS HOMEWORK!!!! IT'S *REALLY* IMPORTANT. We need a letter from EVERY one of you!
Here is the link to the specifics of the assignment, again, just in case:
http://www.usfirst.org/community/frc/content.aspx?id=4066
thanks!
Wednesday, January 31, 2007
Wednesday 31.01.07
today:
started off a bit slow, but then we took the stock over to IDEO to weld!!
yay for Jimmy!
so by the end of the night, we have a FRAME! that's right. a frame...w00t!
meanwhile back at casti, the freshmen designed and put together a bom for bumpers. a much needed and neccesary task :)
Tomorrow:
mounting transmissions from Rosie onto 80-20 prototype so programming can run code on a robot whose transmissions aren't likely to lock up at any moment....yikes.
more welding-specifically ramps, maybe arm structure
drilling holes in chassis frame--so we need to take SPROCKETS AND CHAIN TO IDEO
look to buy FLANGE BEARINGS TO KEEP TRANSMISSION SHAFT FROM TORQUING
prototype with ramp material that ed brought over tonight (metal mesh)
use 80-20 ramp to test with extension DAMPERS and COIL SPRINGS
finalize bumper design--keep it up, freshmen!
HOMEWORK!
EVERY PERSON ON THE ENTIRE ROBOTICS TEAM MUST WRITE A LETTER TO A CONGRESSPERSON, INVITING THEM TO A REGIONAL AND TALKING ABOUT HOW GREAT FIRST IS (cause it's hella rockin').
See http://www.usfirst.org/community/frc/content.aspx?id=4066 for specific details on what you should include.
PLEASE submit your letter to Chrissy, Hannah, or Julia by SATURDAY AFTERNOON, and we'll send it off for you. If you don't care who you write to, just leave that part blank and we'll fill it in or get back to you.
See you all tomorrow--remeber to be there on time (3:30) so that we can get started :) LOTS to do before ship date!!!
thanks!
over and out
started off a bit slow, but then we took the stock over to IDEO to weld!!
yay for Jimmy!
so by the end of the night, we have a FRAME! that's right. a frame...w00t!
meanwhile back at casti, the freshmen designed and put together a bom for bumpers. a much needed and neccesary task :)
Tomorrow:
mounting transmissions from Rosie onto 80-20 prototype so programming can run code on a robot whose transmissions aren't likely to lock up at any moment....yikes.
more welding-specifically ramps, maybe arm structure
drilling holes in chassis frame--so we need to take SPROCKETS AND CHAIN TO IDEO
look to buy FLANGE BEARINGS TO KEEP TRANSMISSION SHAFT FROM TORQUING
prototype with ramp material that ed brought over tonight (metal mesh)
use 80-20 ramp to test with extension DAMPERS and COIL SPRINGS
finalize bumper design--keep it up, freshmen!
HOMEWORK!
EVERY PERSON ON THE ENTIRE ROBOTICS TEAM MUST WRITE A LETTER TO A CONGRESSPERSON, INVITING THEM TO A REGIONAL AND TALKING ABOUT HOW GREAT FIRST IS (cause it's hella rockin').
See http://www.usfirst.org/community/frc/content.aspx?id=4066 for specific details on what you should include.
PLEASE submit your letter to Chrissy, Hannah, or Julia by SATURDAY AFTERNOON, and we'll send it off for you. If you don't care who you write to, just leave that part blank and we'll fill it in or get back to you.
See you all tomorrow--remeber to be there on time (3:30) so that we can get started :) LOTS to do before ship date!!!
thanks!
over and out
Monday, January 29, 2007
Monday 29.01.07 (a lesson in floss)
quick recap...
ALLEN STEEL ROCKS MY SOCKS!
went and got 33 pounds of aluminum today. quite fun. w00t! saw 114 there. quite exciting. the allen is doing well...and so is the horizontal band saw :)
more designing stuff
the ramps are ramping up (haha) and we found some SWEET springs that do the job of the hinges very neatly...though at the moment they are secured rather precariously...but we covered them up and put a nice "do not touch this without safety glasses or else" sign on it so we are good to go.
as for the arm, it is also looking good. more finalizing of design, so basically all we need to do now is put it together. YAYNESS!
tomorrow:IDEO at 5.30. we will be welding a frame, welding an arm, drilling some stuff, laithing some other stuff, and doing generally exciting things.
(vague stuff to be exact)
get EXCITED! the ACTUAL robot is coming together!!!!
over and out
ALLEN STEEL ROCKS MY SOCKS!
went and got 33 pounds of aluminum today. quite fun. w00t! saw 114 there. quite exciting. the allen is doing well...and so is the horizontal band saw :)
more designing stuff
the ramps are ramping up (haha) and we found some SWEET springs that do the job of the hinges very neatly...though at the moment they are secured rather precariously...but we covered them up and put a nice "do not touch this without safety glasses or else" sign on it so we are good to go.
as for the arm, it is also looking good. more finalizing of design, so basically all we need to do now is put it together. YAYNESS!
tomorrow:IDEO at 5.30. we will be welding a frame, welding an arm, drilling some stuff, laithing some other stuff, and doing generally exciting things.
(vague stuff to be exact)
get EXCITED! the ACTUAL robot is coming together!!!!
over and out
Sunday, January 28, 2007
We Have Hit the Halfway Point
Yes, it's true. Something like 21 or 22 more days to go. Eek!
Firstly, thanks to all the freshmen who show up consistently (even for the supposedly nonexistant Sunday meetings) and are ready to help (or be patient when we don't have much for you guys to do). Today was one those days. But while not much progress was made on the building front, Chrissy, Kersten, and I were able to reassess our design and determine the mechanisms that still need figuring out for our final robot.
Here are the lists we came up with.
Little tasks to do:
- Drill new holes/fix existing holes in transmission mounting plate so they actually line up with the holes in the transmission!
- Make pillowblock bearings similar to the ones we have on Rosie (the black boxes--we should remove these tomorrow so we can show Jim). I (Julia) have the new dimensions for these.
- Hollow out the 3/4" diameter arm shaft that weighs a ton (it doesn't need to be completely indestructable)
- Weld the other end piece of the ramp release flipper to a shaft collar so that's it's removable
- Weld a battery mount
- Make Delrin wheels or slide for the end of the ramp so it doesn't snag on the carpet
- Drill holes in gears in transmission adapter for weight loss (we'll hold off on this until we're mounting them on the real chassis)
- Maybe mount electronics board (I said electronics could do this, but we should probably just ask them what they want and maybe drill holes based on where we want them on the chassis)
- Make a cover for the electroncis board or perhaps just cover the front face of the chassis with a sheet of polycarbonate
- Signage (1700, sponsers, too!)
- Bumpers (maybe later...)
To figure out:
- We'd like to make the secondary ramp longer so the angle robots have to drive up isn't so steep (30° is last year's angle and it wasn't ideal), but a big issue is weight! We weighed our prototype (which is missing a fair bit of parts) and it's about 100lb. YIKES!
- Ramp material: how does poly carb weight compare to expanded metal? (we're already planning to build a frame with bracing using aluminum extrusion)
-Where are we going to have spring hinges, regular hinges, dampers for our ramp? Are there dampers that prevent both extremely fast extension and compression? How are we going to position and deploy the TWO supports for each ramp (K, C, and I are thinking just cable to both the main ramp and the secondary ramp that'll force it into one position)? Ideally we'll make progress on this MONDAY AFTERNOON/EVENING AND BE ABLE TO PLACE AN ORDER!! :)
-ASK JIM/ED ABOUT TORSIONAL SPRING DAMPERS (for ramp) (and post pics of sketches for em)
- Make any necessary changes to prototype chassis dimensions and then have Jim weld it for us (as well as the tower of power and the ramp frames)
What we figured out:
-The transmissions mounted generally as they are on the prototype will work on the actual robot (so we only need one chain around the back two wheels--saving weigh, an extra support someone for mounting elsewhere, and messy chain tensioning stuff)
- We don't want to have two-level arm-motor gearing. Remember, KISS (keep it simple, stupid)! A 10 tooth sprocket on the motor and a sprocket with about 70 teeth up on the arm shaft should do the trick, though it'd be good to talk this through with Jim and/or Ed once more.
Tomorrow let's set some deadlines and then jump right in. Kersten is gonna start us out by picking up a whole bunch of aluminum extrusion from Alan Steel tomorrow. How cool would it be to finish our robot 2 weeks before ship date?!
Right, so as I see it, these are crucial things to focus on tomorrow (I may have missed something, so read the other lists, too!):
- The ramp: joints, materials, springs, dampers, cable, height (based on the height of the chassis) ,etc. Ed will be here, so we'll be able to get his input in this area. PLACE AN ORDER!
- Also ORDER a sprocket for the IFI arm
- Contact Jim about a session on Tuesday (and others this week, too)
- Along with the ramps, work on the arm. We don't even have this prototype yet, so let's make sure this is a priority!
--question I just had: can our current design hold a keeper?
See you all tomorrow!
Firstly, thanks to all the freshmen who show up consistently (even for the supposedly nonexistant Sunday meetings) and are ready to help (or be patient when we don't have much for you guys to do). Today was one those days. But while not much progress was made on the building front, Chrissy, Kersten, and I were able to reassess our design and determine the mechanisms that still need figuring out for our final robot.
Here are the lists we came up with.
Little tasks to do:
- Drill new holes/fix existing holes in transmission mounting plate so they actually line up with the holes in the transmission!
- Make pillowblock bearings similar to the ones we have on Rosie (the black boxes--we should remove these tomorrow so we can show Jim). I (Julia) have the new dimensions for these.
- Hollow out the 3/4" diameter arm shaft that weighs a ton (it doesn't need to be completely indestructable)
- Weld the other end piece of the ramp release flipper to a shaft collar so that's it's removable
- Weld a battery mount
- Make Delrin wheels or slide for the end of the ramp so it doesn't snag on the carpet
- Drill holes in gears in transmission adapter for weight loss (we'll hold off on this until we're mounting them on the real chassis)
- Maybe mount electronics board (I said electronics could do this, but we should probably just ask them what they want and maybe drill holes based on where we want them on the chassis)
- Make a cover for the electroncis board or perhaps just cover the front face of the chassis with a sheet of polycarbonate
- Signage (1700, sponsers, too!)
- Bumpers (maybe later...)
To figure out:
- We'd like to make the secondary ramp longer so the angle robots have to drive up isn't so steep (30° is last year's angle and it wasn't ideal), but a big issue is weight! We weighed our prototype (which is missing a fair bit of parts) and it's about 100lb. YIKES!
- Ramp material: how does poly carb weight compare to expanded metal? (we're already planning to build a frame with bracing using aluminum extrusion)
-Where are we going to have spring hinges, regular hinges, dampers for our ramp? Are there dampers that prevent both extremely fast extension and compression? How are we going to position and deploy the TWO supports for each ramp (K, C, and I are thinking just cable to both the main ramp and the secondary ramp that'll force it into one position)? Ideally we'll make progress on this MONDAY AFTERNOON/EVENING AND BE ABLE TO PLACE AN ORDER!! :)
-ASK JIM/ED ABOUT TORSIONAL SPRING DAMPERS (for ramp) (and post pics of sketches for em)
- Make any necessary changes to prototype chassis dimensions and then have Jim weld it for us (as well as the tower of power and the ramp frames)
What we figured out:
-The transmissions mounted generally as they are on the prototype will work on the actual robot (so we only need one chain around the back two wheels--saving weigh, an extra support someone for mounting elsewhere, and messy chain tensioning stuff)
- We don't want to have two-level arm-motor gearing. Remember, KISS (keep it simple, stupid)! A 10 tooth sprocket on the motor and a sprocket with about 70 teeth up on the arm shaft should do the trick, though it'd be good to talk this through with Jim and/or Ed once more.
Tomorrow let's set some deadlines and then jump right in. Kersten is gonna start us out by picking up a whole bunch of aluminum extrusion from Alan Steel tomorrow. How cool would it be to finish our robot 2 weeks before ship date?!
Right, so as I see it, these are crucial things to focus on tomorrow (I may have missed something, so read the other lists, too!):
- The ramp: joints, materials, springs, dampers, cable, height (based on the height of the chassis) ,etc. Ed will be here, so we'll be able to get his input in this area. PLACE AN ORDER!
- Also ORDER a sprocket for the IFI arm
- Contact Jim about a session on Tuesday (and others this week, too)
- Along with the ramps, work on the arm. We don't even have this prototype yet, so let's make sure this is a priority!
--question I just had: can our current design hold a keeper?
See you all tomorrow!
Saturday, January 27, 2007
Hurrah!
Lots of progress today!
The prototype chassis is ready for some code and an electronics board! We finished mounting the transmissions and putting chain on and also mounted the motor for the ramp release mechanism! Kersten and I also rigged up a battery mount for the prototype chassis made out of good old wood and angle iron :)
Thanks again to Jim for the hollowed-out Delrin "chain tensioning" rods and for taking Kersten, Chrissy, Anne, and Melissa to the shop to help us:
-Cut chain to length
-Get some polycarbonate for the electronics board (if any of you programming/electronics people are reading this, all you have to do is mount your stuff onto this sheet, which has already been cut to size)
-Mill a slot for a key in the arm shaft
-Drill holes for set screws in the transmission sprockets
-And probably other things I'm not aware of since I didn't go
Meanwhile, Nandini learned about putting chain together with half-links and master-links. yay!
See you all tomorrow at 11:00 (get ready to work on the arm and the crate)!
ps--PLEASE reply to my email re Portland by tomorrow (Sunday) afternoon if you haven't already!
The prototype chassis is ready for some code and an electronics board! We finished mounting the transmissions and putting chain on and also mounted the motor for the ramp release mechanism! Kersten and I also rigged up a battery mount for the prototype chassis made out of good old wood and angle iron :)
Thanks again to Jim for the hollowed-out Delrin "chain tensioning" rods and for taking Kersten, Chrissy, Anne, and Melissa to the shop to help us:
-Cut chain to length
-Get some polycarbonate for the electronics board (if any of you programming/electronics people are reading this, all you have to do is mount your stuff onto this sheet, which has already been cut to size)
-Mill a slot for a key in the arm shaft
-Drill holes for set screws in the transmission sprockets
-And probably other things I'm not aware of since I didn't go
Meanwhile, Nandini learned about putting chain together with half-links and master-links. yay!
See you all tomorrow at 11:00 (get ready to work on the arm and the crate)!
ps--PLEASE reply to my email re Portland by tomorrow (Sunday) afternoon if you haven't already!
Thursday, January 25, 2007
Thursday 25.01.2007
hey hey hey!
while the programming team had commandeered the transmissions, we worked on designing a motor mount for the arm mechanism (there are some very nice drawings in GENERAL 2), as well as putting together the new wheel and putting it on!
Sent j-rock on an ace run for washers and shaft collars (we never seem to have enough...hmmm...who has been eating the shaft collars???)
so now we have washers so the shaft collars are not as hard to install on the wheels.
made a list of very important measurements. arms stuff. chassis stuff. other stuff.
and now we are about to mount the transmissions on the robot! yay for chain!
Doug, Richard, and Beth are working on the RACK! w00t! go them!
GOALS: end of the week (saturday at the latest) have a running prototype. yay!
REMINDER! PLEASE COME TO TOMORROW'S BUILD-PROGRAMMING-MENTOR MEETING AT 5.30. WE WILL BE DISCUSSING THE REST OF THE SEASON AND WHAT WE NEED FROM EACH OTHER TO ACCOMPLISH OUR GOAL!!!
THANKS.
over and out.
while the programming team had commandeered the transmissions, we worked on designing a motor mount for the arm mechanism (there are some very nice drawings in GENERAL 2), as well as putting together the new wheel and putting it on!
Sent j-rock on an ace run for washers and shaft collars (we never seem to have enough...hmmm...who has been eating the shaft collars???)
so now we have washers so the shaft collars are not as hard to install on the wheels.
made a list of very important measurements. arms stuff. chassis stuff. other stuff.
and now we are about to mount the transmissions on the robot! yay for chain!
Doug, Richard, and Beth are working on the RACK! w00t! go them!
GOALS: end of the week (saturday at the latest) have a running prototype. yay!
REMINDER! PLEASE COME TO TOMORROW'S BUILD-PROGRAMMING-MENTOR MEETING AT 5.30. WE WILL BE DISCUSSING THE REST OF THE SEASON AND WHAT WE NEED FROM EACH OTHER TO ACCOMPLISH OUR GOAL!!!
THANKS.
over and out.
Monday, January 22, 2007
Monday 22.01.2007
welcome to the third week!
got the new transmission adapter in the mail today, along with some 80-20 and some other cool stuff. w00t!
we started by cleaning the project room (a much needed action)
we can actually walk in in now without tripping over things (mostly) and melissa organized boxes and pens while kersten, nandini, and anne worked on inventoring the shipment as well as designing more ramp stuff.
then it was off to IDEO for a transmission-putting-together-taking-off-random-stuff-from-the CIM-motor-delrin-cutting-shaft-widening-laithing-filing extravaganza with jimmy (thank you!)
after getting back, and eating (wonderful dinner supplied by the macewan family), we worked on ramp stuff with ed, while doug and mr. crone worked on the rack downstairs.
currently working on ramp. more later.
AS A REMINDER, MEETING TIMES HAVE BEEN EXTENDED FROM 3.30 TO 8PM. PLEASE BE HERE. WE ARE IN THE FINAL STAGES OF DESIGN AND BUILD SO IF YOU WANT TO BE A PART OF THE ACTION, BE HERE. plus it's fun... :) yay!
over and out.
-chrissy
got the new transmission adapter in the mail today, along with some 80-20 and some other cool stuff. w00t!
we started by cleaning the project room (a much needed action)
we can actually walk in in now without tripping over things (mostly) and melissa organized boxes and pens while kersten, nandini, and anne worked on inventoring the shipment as well as designing more ramp stuff.
then it was off to IDEO for a transmission-putting-together-taking-off-random-stuff-from-the CIM-motor-delrin-cutting-shaft-widening-laithing-filing extravaganza with jimmy (thank you!)
after getting back, and eating (wonderful dinner supplied by the macewan family), we worked on ramp stuff with ed, while doug and mr. crone worked on the rack downstairs.
currently working on ramp. more later.
AS A REMINDER, MEETING TIMES HAVE BEEN EXTENDED FROM 3.30 TO 8PM. PLEASE BE HERE. WE ARE IN THE FINAL STAGES OF DESIGN AND BUILD SO IF YOU WANT TO BE A PART OF THE ACTION, BE HERE. plus it's fun... :) yay!
over and out.
-chrissy
Sunday, January 21, 2007
Sunday 21.01.07
ok so today...
jimmy came over to casti and talked about arm stuff (mostly sprockets and gearing down that monster of a CIM motor) and ramp stuff...
we tested the ramp stuff...and the hinges aren't really working, so we are going over to ideo tomorrow with a to-do list and a bunch of stuff to check out! yay!
thanks to trae for working with the programmers today! they worked a bunch with the electronics board that emily made.
speaking of emily, we also skyped her around 3. she says good job and keep up the good work!
Doug and a bunch of the parents were working hard on the rack...sawdust flying everywhere! the crate is half-finished and the rack is all ready to put together! yay!
see you all tomorrow at the new meeting time, 3:30
be there or be not there (and tell us)
jimmy came over to casti and talked about arm stuff (mostly sprockets and gearing down that monster of a CIM motor) and ramp stuff...
we tested the ramp stuff...and the hinges aren't really working, so we are going over to ideo tomorrow with a to-do list and a bunch of stuff to check out! yay!
thanks to trae for working with the programmers today! they worked a bunch with the electronics board that emily made.
speaking of emily, we also skyped her around 3. she says good job and keep up the good work!
Doug and a bunch of the parents were working hard on the rack...sawdust flying everywhere! the crate is half-finished and the rack is all ready to put together! yay!
see you all tomorrow at the new meeting time, 3:30
be there or be not there (and tell us)
Saturday, January 20, 2007
Groups!
Hey everyone!
Today we worked more on everything. We split into teams, so Chrissy and Nandini worked on the arm prototype and then the batteries, Julia and Anne worked on the 80-20 version of the ramp prototype, Kersten and Melissa worked with Doug on the flipper things to hold in the new ramps, and the freshman all worked on the crate or rack at some point during the day.
So the ramp people still need to attach the ramp and figure out how the springs should work, the arm people need to see what sprocket they want to use, and the flipper people are mainly waiting on the order to arrive so they can start work.
And the crate is doing well- the back half is attached to the base.
Meeting tomorrow is from 11 to sometime before 6 (probably around 3 or 4).
Today we worked more on everything. We split into teams, so Chrissy and Nandini worked on the arm prototype and then the batteries, Julia and Anne worked on the 80-20 version of the ramp prototype, Kersten and Melissa worked with Doug on the flipper things to hold in the new ramps, and the freshman all worked on the crate or rack at some point during the day.
So the ramp people still need to attach the ramp and figure out how the springs should work, the arm people need to see what sprocket they want to use, and the flipper people are mainly waiting on the order to arrive so they can start work.
And the crate is doing well- the back half is attached to the base.
Meeting tomorrow is from 11 to sometime before 6 (probably around 3 or 4).
Thursday, January 18, 2007
Do it.
Chrissy and Julia made a run to Ace Hardware during period 6 today and bought door hinges, wheel axle/bolts (6") and nylon nuts to go along with them, steel (?) cable, washers, and maybe a few other things... When Ed came, he brought more steel cable, crimps for the cable, and eye-bolts (I don't actually know what these are called).
The proto chassis now has wheels and a ramp (pictures coming)! The ramp is made out of foamcore mounted on spring hinges and has a damper/support-component, too. Watch the magic unfold...and the foam core break apart. It's not a big deal, but it means we've entered the next stage in the ramp prototyping process: creating an 80-20 frame for the ramp. Not only will this give us a much more realistic sense of weight, it also will make for a much more durable product.
There's also a lot to be done in every other area of the robot--the arm/tower and chassis. Ed helped us break these to-dos into separate tasks with deadlines (see the white board), and we'll each be focusing on two of these for the next while.
And, finally, Kersten learned the importance of "saftey".
The proto chassis now has wheels and a ramp (pictures coming)! The ramp is made out of foamcore mounted on spring hinges and has a damper/support-component, too. Watch the magic unfold...and the foam core break apart. It's not a big deal, but it means we've entered the next stage in the ramp prototyping process: creating an 80-20 frame for the ramp. Not only will this give us a much more realistic sense of weight, it also will make for a much more durable product.
There's also a lot to be done in every other area of the robot--the arm/tower and chassis. Ed helped us break these to-dos into separate tasks with deadlines (see the white board), and we'll each be focusing on two of these for the next while.
And, finally, Kersten learned the importance of "saftey".
Wednesday, January 17, 2007
Oh man (good stuff and not so good)
Accomplishments:
-holes for wheel axles and delrin rod chain tensioners drilled through bottom 80-20 chassis rails by jim
-IFI wheel and treads purchased
-2 banebot transmission adaptors purchased
-chassis and arm 80-20 structures completed (almost--see pictures by following "Build Team Photos" link and selecting Prototypes album)
-some foam core cut for ramps
Discoveries:
-Something went weird with our predicted axle lengths. The ones we've used in past years weren't long enough, so Chrissy and I are making a trip to Ace tomorrow during p. 6 to buy some (and other ramp, etc. parts, too)
-L brackets are too long for the planned 3.5" between the chassis rails around the wheels (L-brackets are 2"-see pictures). We used L-brackets cut down to 1x2 holes, but only had 3, so we need to cut another tomorrow.
To do/buy/figure out:
-Do we have enough chain for our chassis? (When we hand it over to programming, it should have motors and chain, so we can have a working chassis)
-everything ramp related
-washers so the spring hinges aren't floating around on bolts prevented from screwing into nut plates further because they're hitting the 80-20 on the other side of the nut plate
-cut a hole off an L-bracket for the chassis
-(grippers)
-Comment if you think of anything else that needs to be done soon!
Announcements:
-New meeting times (see side bar)
-We're meeting 3-4 on Friday, and on Saturday (10-4) AND Sunday (starting 11)
Bad news:
-um, let's just say everyone should read the game manual (but don't freak out, please)
-get ready to do some brainstorming...
on that note, see you tomorrow and get ready for a productive meeting :)
-holes for wheel axles and delrin rod chain tensioners drilled through bottom 80-20 chassis rails by jim
-IFI wheel and treads purchased
-2 banebot transmission adaptors purchased
-chassis and arm 80-20 structures completed (almost--see pictures by following "Build Team Photos" link and selecting Prototypes album)
-some foam core cut for ramps
Discoveries:
-Something went weird with our predicted axle lengths. The ones we've used in past years weren't long enough, so Chrissy and I are making a trip to Ace tomorrow during p. 6 to buy some (and other ramp, etc. parts, too)
-L brackets are too long for the planned 3.5" between the chassis rails around the wheels (L-brackets are 2"-see pictures). We used L-brackets cut down to 1x2 holes, but only had 3, so we need to cut another tomorrow.
To do/buy/figure out:
-Do we have enough chain for our chassis? (When we hand it over to programming, it should have motors and chain, so we can have a working chassis)
-everything ramp related
-washers so the spring hinges aren't floating around on bolts prevented from screwing into nut plates further because they're hitting the 80-20 on the other side of the nut plate
-cut a hole off an L-bracket for the chassis
-(grippers)
-Comment if you think of anything else that needs to be done soon!
Announcements:
-New meeting times (see side bar)
-We're meeting 3-4 on Friday, and on Saturday (10-4) AND Sunday (starting 11)
Bad news:
-um, let's just say everyone should read the game manual (but don't freak out, please)
-get ready to do some brainstorming...
on that note, see you tomorrow and get ready for a productive meeting :)
Tuesday, January 16, 2007
Building--hurrah
Our order arrived from Mcmaster today! Lots of fun stuff :)
Chrissy and crew piled into a convertible bug with the 8' and 6' long pieces of 80-20 (what a sight) and made a visit to IDEO. Jim cut the 80-20 to length (thanks, Jim!), and the assembling has begun.
Accomplished so far:
-80/20 for arm, tower, and chassis cut to length
-Chassis assembled except for bottom layer (with the wheels, etc)
To do:
-assemble arm/tower
-drill 3/8" holes in pieces of 80/20 for wheel axles (I started drilling 1/4" pilot holes, but stopped when I realized that the shape of 80/20 means that they won't actually be able to function as pilot holes). Plan 2) Make another visit to Jim tomorrow or Thursday to get this holes drilled. If he's unavailable, do it in our shop... Whoever does this, remember that the holes for the middle wheels have to be 1/8" lower.
-assemble bottom of chassis with wheels/axles and put together with the rest of chassis
-tape together sheets of foamcore to make a thicker piece to use as a ramp
Other decisions made/things to purchase:
-We're going to buy the adaptor that allows us to use 2 CIM motors with one transmission box (we have the additional 2 CIM motors already from previous years)
-Buy one 8" dia, 1" wide IFI wheel, but we do NOT need any more sprockets (and we're not going to invest in larger sprockets either to gear down anything--Ed says we'll be ok)
-Buy seven 1" wide wedgetop treads for IFI wheels (fyi, website doesn't work on macs...sheesh)
Last comments:
-WE NEED TO MAKE COPIES OF BLUEPRINTS SO THAT EVEN WHEN SOMEONE AND HER NOTEBOOK IS GONE, WE STILL KNOW HOW TO BUILD OUR ROBOT :) I'll make sure this gets done tomorrow.
-Our Friday meeting is going to be shorter than usual...exact time tbd.
That's all for now. Hope you all don't have too much homework!
ps-Ed was here tonight, if I didn't make that clear. thanks, Ed.
Chrissy and crew piled into a convertible bug with the 8' and 6' long pieces of 80-20 (what a sight) and made a visit to IDEO. Jim cut the 80-20 to length (thanks, Jim!), and the assembling has begun.
Accomplished so far:
-80/20 for arm, tower, and chassis cut to length
-Chassis assembled except for bottom layer (with the wheels, etc)
To do:
-assemble arm/tower
-drill 3/8" holes in pieces of 80/20 for wheel axles (I started drilling 1/4" pilot holes, but stopped when I realized that the shape of 80/20 means that they won't actually be able to function as pilot holes). Plan 2) Make another visit to Jim tomorrow or Thursday to get this holes drilled. If he's unavailable, do it in our shop... Whoever does this, remember that the holes for the middle wheels have to be 1/8" lower.
-assemble bottom of chassis with wheels/axles and put together with the rest of chassis
-tape together sheets of foamcore to make a thicker piece to use as a ramp
Other decisions made/things to purchase:
-We're going to buy the adaptor that allows us to use 2 CIM motors with one transmission box (we have the additional 2 CIM motors already from previous years)
-Buy one 8" dia, 1" wide IFI wheel, but we do NOT need any more sprockets (and we're not going to invest in larger sprockets either to gear down anything--Ed says we'll be ok)
-Buy seven 1" wide wedgetop treads for IFI wheels (fyi, website doesn't work on macs...sheesh)
Last comments:
-WE NEED TO MAKE COPIES OF BLUEPRINTS SO THAT EVEN WHEN SOMEONE AND HER NOTEBOOK IS GONE, WE STILL KNOW HOW TO BUILD OUR ROBOT :) I'll make sure this gets done tomorrow.
-Our Friday meeting is going to be shorter than usual...exact time tbd.
That's all for now. Hope you all don't have too much homework!
ps-Ed was here tonight, if I didn't make that clear. thanks, Ed.
Monday, January 15, 2007
One more day...
Word has it that our order is arriving tomorrow! If it does in fact come, at least a few of us will be making a trip to IDEO (arriving at 5:30) where Jim has agreed to cut it for us.
In the meantime, we've been sending out emails and all that good (but not so interesting) stuff. We also took a look at this year's new transmissions, and we're hoping to use 4 cim motors, 2 per side, to drive our robot. Each gearbox FIRST provided in the KOP only hooks up to one motor, so our two options are:
1) buy 2 adaptors that'll allow us to run one transmission with two CIM motors
2) buy 2 more transmission gearboxes so we have a total of 4 (this poses some mounting issues...)
Ah yes--and thanks to Allie and Nandini for starting in on estimating the weight of our prototype! We're definitely going to need to keep track of this throughout the season!
Please check your email if you haven't recently and respond to my email about travel. I (Julia) need answers from everyone by tomorrow morning at the latest--thanks to those who already replied!
see ya!
In the meantime, we've been sending out emails and all that good (but not so interesting) stuff. We also took a look at this year's new transmissions, and we're hoping to use 4 cim motors, 2 per side, to drive our robot. Each gearbox FIRST provided in the KOP only hooks up to one motor, so our two options are:
1) buy 2 adaptors that'll allow us to run one transmission with two CIM motors
2) buy 2 more transmission gearboxes so we have a total of 4 (this poses some mounting issues...)
Ah yes--and thanks to Allie and Nandini for starting in on estimating the weight of our prototype! We're definitely going to need to keep track of this throughout the season!
Please check your email if you haven't recently and respond to my email about travel. I (Julia) need answers from everyone by tomorrow morning at the latest--thanks to those who already replied!
see ya!
Sunday, January 14, 2007
Stuff ordered
Today we met and ordered the stuff we need to prototype from McMaster. It should be here in a day or two, and then we can start building.
We also skyped Emily, who answered some or our questions about general stuff.
That's about it. See you tomorrow!
We also skyped Emily, who answered some or our questions about general stuff.
That's about it. See you tomorrow!
Saturday, January 13, 2007
Crate and FINAL BoMs
YAY! Our drawings and BoMs for the prototypes are done, we will order the materials tomorrow, and we can finally start building them when the parts arrive this week... only a few days behind schedule.
We also sent an expedition to buy the materials for the new crate, after which Mr Reichling and George Schnurle helped the freshmen with building. If any of you freshmen reading this want to elaborate on that or can say what the current crate situation is, feel free to comment or post.
We'll send out an email later tonight saying when we're meeting tomorrow.
Cheer(io)s!
We also sent an expedition to buy the materials for the new crate, after which Mr Reichling and George Schnurle helped the freshmen with building. If any of you freshmen reading this want to elaborate on that or can say what the current crate situation is, feel free to comment or post.
We'll send out an email later tonight saying when we're meeting tomorrow.
Cheer(io)s!
Friday, January 12, 2007
BoMs, blueprints, prototypes, and mechanisms
Today we worked more on the prototyping process. The design for one of the gripper ideas was finalized, and we managed to actually build a working model. It looks like a nice, simple gripper that could work well for us. The ramp-holding mechanism was ironed out and sort of sketched out (to be completely blueprinted tomorow). Since most of the BoMs are done for the three big prototypes (chassis, arm/tower, and ramps), we started compiling them and figuring out what we already have (esp in the 80-20 dept) so we can send in an order tomorrow.
Ed stopped by and reminded us that our drawings were actually rather insufficient (and so were our design specifics), so then we went and worked on them. We now know how we're going to hinge ramp stuff (like, the alignment and mechanisms for the support and secondary ramp), what the tower will look like (that's been modified), and what our prototype chassis will be (80-20) (it was under some contention earlier).
If you want to know the exciting changes that we made, come to the meeting tomorrow from 10-3!
Also, crate materials shopping will be starting at 11, so hopefully we will have fun with that and have some of the crate finished by the end of the meeting.
Cheers!
Ed stopped by and reminded us that our drawings were actually rather insufficient (and so were our design specifics), so then we went and worked on them. We now know how we're going to hinge ramp stuff (like, the alignment and mechanisms for the support and secondary ramp), what the tower will look like (that's been modified), and what our prototype chassis will be (80-20) (it was under some contention earlier).
If you want to know the exciting changes that we made, come to the meeting tomorrow from 10-3!
Also, crate materials shopping will be starting at 11, so hopefully we will have fun with that and have some of the crate finished by the end of the meeting.
Cheers!
Thursday, January 11, 2007
Blueprints continuing to progress
Today we met with Mr Reichling to talk about our crate. It's looking pretty good and we will go buy stuff and maybe start working on it on Saturday.
After that we worked more on blueprints and BoMs for the arm idea (having nixed (for now) the elevator idea), the ramp idea, and the various grippers. Melissa now knows all we will ever need to know about solenoids, Ida, Anne, and Alecia worked on modifying our 'harpoon' gripper and started a BoM for that, Julia worked on the chassis sketch and BoM, and Nandini and I worked on this ramp thing that we're going to do.
Everybody, try to keep thinking of gripper designs that we can put on the end of our rotating arm. If you're lying awake tonight or eating lunch tomorrow or bored during tomorrow's meeting, try to think of ways to manipulate inner tubes that don't require any motors- we're all for simple, passive devices that don't require as much designing and are more reliable.
That's all for now- see you tomorrow.
After that we worked more on blueprints and BoMs for the arm idea (having nixed (for now) the elevator idea), the ramp idea, and the various grippers. Melissa now knows all we will ever need to know about solenoids, Ida, Anne, and Alecia worked on modifying our 'harpoon' gripper and started a BoM for that, Julia worked on the chassis sketch and BoM, and Nandini and I worked on this ramp thing that we're going to do.
Everybody, try to keep thinking of gripper designs that we can put on the end of our rotating arm. If you're lying awake tonight or eating lunch tomorrow or bored during tomorrow's meeting, try to think of ways to manipulate inner tubes that don't require any motors- we're all for simple, passive devices that don't require as much designing and are more reliable.
That's all for now- see you tomorrow.
Wednesday, January 10, 2007
Blueprints in progress
Today we inventoried the 80-20 parts we already have and made progress on blueprints. In the process of doing so, we decided on the following dimensions:
chassis--
27"x 37" with the top at a height of 12.5" (so this includes wheel radius)
(for the prototype, we'll still use the slightly large welded frame we have and mount an 80-20 frame of the right dimensions on top)
rotating arm "tower of power"--
44" from the top of the chassis to the height at which the sprocket is mounted (near the top of the arm-frame tower). We estimated a sprocket of max diameter 5", so presumably as much as 2.5" will extend beyond this height). This gives us an estimated robot height of 59" (12.5"+44"+2.5").
Don't forget to draw a blueprint (with dimensions and the 3 perspectives we talked about) of one of the grippers we want to prototype (or a variation on a design we've discussed that you think might work well)!
chassis--
27"x 37" with the top at a height of 12.5" (so this includes wheel radius)
(for the prototype, we'll still use the slightly large welded frame we have and mount an 80-20 frame of the right dimensions on top)
rotating arm "tower of power"--
44" from the top of the chassis to the height at which the sprocket is mounted (near the top of the arm-frame tower). We estimated a sprocket of max diameter 5", so presumably as much as 2.5" will extend beyond this height). This gives us an estimated robot height of 59" (12.5"+44"+2.5").
Don't forget to draw a blueprint (with dimensions and the 3 perspectives we talked about) of one of the grippers we want to prototype (or a variation on a design we've discussed that you think might work well)!
Tuesday, January 09, 2007
Before we Prototype...
We now have two major arm designs--rotating arm & elevator-forklift--ideas that we plan to now prototype (if reaching the floor with an elevator-forklift design doesn't become to much of a problem) and grippers to test with those arms. We also have 2 ramp ideas we want to try out.
So, stuff to prototype:
- hi-mounted rotating arm
- elevator/forklift
- grippers to test with above arms
- 2 ramp ideas
Before we prototype, there are some important things to do first:
- Create blueprints (not Kersten-Julia-Chrissy sketches) for the two arm designs with side, front, and top views (dimensions and all that good stuff, too)
- Also make blueprints for the different grippers
- Come up with BoM (Bill of Materials)--stuff we need to build prototypes
- Inventory parts we have (like 80-20 L-brackets, bearings & steel rod for the rotating arm?), so we don't spend $ unnecessarily
- Enlarge our calendar, so that we can coordinate with Prog/Electronics on the same calendar.
Other robot info:
- The length of a rotating arm will be roughly 5' (we have better numbers than this)
- To build our prototype chassis, we're going to use our pre-season welded chassis frame for the lower level. The rest of it will be 80-20 (to be purchased)
Ed showed me (julia) some Solidworks basics last night, so we'll be able to model our robot this year. (A cool thought from Ed: if FIRST has modeled the rack, we can get an idea for how our robot design will interact with the rack all on the computer).
Lastly, we still a parent to help us build the Rack (field element). We're pretty sure we've found a place to put it (the cafeteria), so please reply ASAP if you can help out (an email also went out to parents about this). Students, please ask your parents if they can help out!
So, stuff to prototype:
- hi-mounted rotating arm
- elevator/forklift
- grippers to test with above arms
- 2 ramp ideas
Before we prototype, there are some important things to do first:
- Create blueprints (not Kersten-Julia-Chrissy sketches) for the two arm designs with side, front, and top views (dimensions and all that good stuff, too)
- Also make blueprints for the different grippers
- Come up with BoM (Bill of Materials)--stuff we need to build prototypes
- Inventory parts we have (like 80-20 L-brackets, bearings & steel rod for the rotating arm?), so we don't spend $ unnecessarily
- Enlarge our calendar, so that we can coordinate with Prog/Electronics on the same calendar.
Other robot info:
- The length of a rotating arm will be roughly 5' (we have better numbers than this)
- To build our prototype chassis, we're going to use our pre-season welded chassis frame for the lower level. The rest of it will be 80-20 (to be purchased)
Ed showed me (julia) some Solidworks basics last night, so we'll be able to model our robot this year. (A cool thought from Ed: if FIRST has modeled the rack, we can get an idea for how our robot design will interact with the rack all on the computer).
Lastly, we still a parent to help us build the Rack (field element). We're pretty sure we've found a place to put it (the cafeteria), so please reply ASAP if you can help out (an email also went out to parents about this). Students, please ask your parents if they can help out!
Sunday, January 07, 2007
Sunday, Jan 7
Hello!
So today the build and programming teams met. The build team did some brainstorming and prototyping, and we've clarified and narrowed down some of our design ideas. If you haven't seen the project calendar with all the deadlines, take a look. It's on the board in the project room.
We also talked with Emily today and discussed our designs.
See you tomorrow!
So today the build and programming teams met. The build team did some brainstorming and prototyping, and we've clarified and narrowed down some of our design ideas. If you haven't seen the project calendar with all the deadlines, take a look. It's on the board in the project room.
We also talked with Emily today and discussed our designs.
See you tomorrow!
Saturday, December 23, 2006
Get Excited for 2007!
Hello Team!
Thank you so much for signing up for Castilleja's Robotics Team: FIRST
Team 1700!
This will be our third season as a team, and we expect to rock! This email will outline the major dates for the 2007 season, what to expect and how to get involved. Please look it over, mark your calendars, and get psyched!
FIRST (For Inspiration and Recognition of Science and Technology), was founded in 1992 by Dean Kamen, "To create a world where science and technology are celebrated... where young people dream of becoming science and technology heroes". In 2006, its flagship program, the FIRST Robotics Competition, reached more than 28,000 high school students on
1,133 teams in 33 regional competitions. FIRST's multinational competition teams professionals and young people to solve an engineering design problem in an intense and competitive way. Its goal is to motivate young people to pursue education and career opportunities in science, technology, engineering, and math, while building self-confidence, knowledge, and life skills. Check out the website:
http://www.usfirst.org/community/frc/
Sat Jan 6, 2007 KICK OFF DAY! Meet at Castilleja, in the Choral Room, at 12 noon. Team leaders will be returning from San Jose State with the Challenge Announcement, Game Rules, and the Kit of Parts. Be ready to brainstorm, inventory all the cool gadgets and gizmos, and start working on the challenge. Plan on working with the team until 5pm. ALL PARENTS
are urged to stay at 12 noon for a special parent meeting to discuss team supervision, meals and logistics. Be there or be square - Lunch will be served!
As a reminder, the kick off day is the SATURDAY BEFORE school starts. Although we would love if everyone could come, we also realize that some of you might be away of vacation. Please let us know ASAP if you are unable to attend.
Sun Jan 7, 11 am to 5pm - continue brainstorming/ possibly prototype the robot.
Mon - Fri, Jan 8 - 14 (Global Week) We will meet daily after school 4 - 7 pm to work on the Challenge.
The team will work daily in the evenings after school, and weekends, to prototype and build the robot, develop the programming that controls it, create the team web site, and our team animation entry. Find the project that interests you most, work hard and HAVE FUN! We ask that Parents help provide supervision and meals.
Feb 20, 2007 Robot Shipping Deadline - Fed Ex will pick up our Robot by 5pm. Please note that the Ship Date is during Ski Week. This is usually the most intense time for build and programming, so we ask that everyone be here for it.
Feb 22, 2007 Website Design Deadline - our Website is up for Award consideration.
March 1 - 3, 2007 Pacific Northwest Regional FIRST competition in Portland, Oregon.
About a dozen team members will go. This is where we won the KPCB Entrepreneurship award in 2006.
March 15 - 17, 2007 Silicon Valley Regional FIRST competition at San Jose State Event Center.
All team members participate in this exciting tournament. This is where we won another KPCB Entrepreneurship award, and
the Engineering Inspiration Award in 2006.
April 12 -14, 2007 FIRST National Championships in Atlanta, Georgia.
About a dozen team members will go. This is where we won the Daimler Chrysler Team Spirit Award in 2006. Keep in mind that the Nationals are during the second weekend of spring Spring Break (meaning that we will leave the wednesday of break).
We'd love for the whole team to go to the out-of-town competitions, but unfortunately that is not financially or organizationally feasible. Team members will qualify to attend the out-of-state tournaments by hard work and dedication to meeting the goals of the team and through their "gracious professionalism."
Thank You and GET EXCITED!
PLEASE send me an e-mail saying that you have read this, and let me know if you are able to make it to kickoff, a simple yes or no in the subject line will suffice :)
THANK YOU!!!
Team Lead
-Chrissy Crone
(Cell: 650-339-2028)
Technical Lead
-Julia Lee
(Cell: 408-482-5196)
Non-Technical Lead
-Hannah Sachs
(Cell: 650-248-8687)
Thank you so much for signing up for Castilleja's Robotics Team: FIRST
Team 1700!
This will be our third season as a team, and we expect to rock! This email will outline the major dates for the 2007 season, what to expect and how to get involved. Please look it over, mark your calendars, and get psyched!
FIRST (For Inspiration and Recognition of Science and Technology), was founded in 1992 by Dean Kamen, "To create a world where science and technology are celebrated... where young people dream of becoming science and technology heroes". In 2006, its flagship program, the FIRST Robotics Competition, reached more than 28,000 high school students on
1,133 teams in 33 regional competitions. FIRST's multinational competition teams professionals and young people to solve an engineering design problem in an intense and competitive way. Its goal is to motivate young people to pursue education and career opportunities in science, technology, engineering, and math, while building self-confidence, knowledge, and life skills. Check out the website:
http://www.usfirst.org/community/frc/
Sat Jan 6, 2007 KICK OFF DAY! Meet at Castilleja, in the Choral Room, at 12 noon. Team leaders will be returning from San Jose State with the Challenge Announcement, Game Rules, and the Kit of Parts. Be ready to brainstorm, inventory all the cool gadgets and gizmos, and start working on the challenge. Plan on working with the team until 5pm. ALL PARENTS
are urged to stay at 12 noon for a special parent meeting to discuss team supervision, meals and logistics. Be there or be square - Lunch will be served!
As a reminder, the kick off day is the SATURDAY BEFORE school starts. Although we would love if everyone could come, we also realize that some of you might be away of vacation. Please let us know ASAP if you are unable to attend.
Sun Jan 7, 11 am to 5pm - continue brainstorming/ possibly prototype the robot.
Mon - Fri, Jan 8 - 14 (Global Week) We will meet daily after school 4 - 7 pm to work on the Challenge.
The team will work daily in the evenings after school, and weekends, to prototype and build the robot, develop the programming that controls it, create the team web site, and our team animation entry. Find the project that interests you most, work hard and HAVE FUN! We ask that Parents help provide supervision and meals.
Feb 20, 2007 Robot Shipping Deadline - Fed Ex will pick up our Robot by 5pm. Please note that the Ship Date is during Ski Week. This is usually the most intense time for build and programming, so we ask that everyone be here for it.
Feb 22, 2007 Website Design Deadline - our Website is up for Award consideration.
March 1 - 3, 2007 Pacific Northwest Regional FIRST competition in Portland, Oregon.
About a dozen team members will go. This is where we won the KPCB Entrepreneurship award in 2006.
March 15 - 17, 2007 Silicon Valley Regional FIRST competition at San Jose State Event Center.
All team members participate in this exciting tournament. This is where we won another KPCB Entrepreneurship award, and
the Engineering Inspiration Award in 2006.
April 12 -14, 2007 FIRST National Championships in Atlanta, Georgia.
About a dozen team members will go. This is where we won the Daimler Chrysler Team Spirit Award in 2006. Keep in mind that the Nationals are during the second weekend of spring Spring Break (meaning that we will leave the wednesday of break).
We'd love for the whole team to go to the out-of-town competitions, but unfortunately that is not financially or organizationally feasible. Team members will qualify to attend the out-of-state tournaments by hard work and dedication to meeting the goals of the team and through their "gracious professionalism."
Thank You and GET EXCITED!
PLEASE send me an e-mail saying that you have read this, and let me know if you are able to make it to kickoff, a simple yes or no in the subject line will suffice :)
THANK YOU!!!
Team Lead
-Chrissy Crone
(Cell: 650-339-2028)
Technical Lead
-Julia Lee
(Cell: 408-482-5196)
Non-Technical Lead
-Hannah Sachs
(Cell: 650-248-8687)
Thursday, December 14, 2006
More cool stuff
photos from our trip to IDEO (and more)!
check out Jim's awesome shadow on the wall (in the welding fieldtrip album):
http://picasaweb.google.com/castilleja.robotics
check out Jim's awesome shadow on the wall (in the welding fieldtrip album):
http://picasaweb.google.com/castilleja.robotics
Field Trip to Ideo + WELDING
so today we (kersten, julia, and chrissy) brought the crew (nandini, melissa, ida, caroline, mary, and sherri)to ideo to 1. show them around the shop and 2. watch jimmy (who most generously skipped his meeting)weld the side rails onto the prototype chassis, so now it is all (most) ready to put wheels on.
upon return to casti, we got to work drilling holes for wheels, playing with the electronics board, taking the old tread off the wheels and putting the spiffy new tread on. we're also working on putting together some new wheels, so yay!
have i mentioned how excited for the season i am?
...
i am SO excited for the season!!!
upon return to casti, we got to work drilling holes for wheels, playing with the electronics board, taking the old tread off the wheels and putting the spiffy new tread on. we're also working on putting together some new wheels, so yay!
have i mentioned how excited for the season i am?
...
i am SO excited for the season!!!
Friday, December 08, 2006
Field Trip to Alan Steel!
Today we went to alan steel. As usual, it was a ton of fun and we saw some really neat stuff. We also bought the additional aluminum we need to finish building the prototype chassis, so we can move forward with that next week. We'll also put treads on the new wheels because we bought a hose clamp! Get excited!
Happy Birthday, Erin.
Happy Birthday, Erin.
Thursday, December 07, 2006
1st Build Meeting!
YAY! The build team has met!
Tursday night we convened in the project room in the science wing (not the presentation rooms, fyi) from 5-7, as usual. Thanks to Nandini, Caroline, Sherri, and Melissa for showing up. We took the wheels we are going to re-use off Rosie (last year's robot) and assembled the other wheels to be used for this year's robot. We also drilled more holes in the proto-type chassis. Yep, lots of hands-on work : ) Hooray!
Tursday night we convened in the project room in the science wing (not the presentation rooms, fyi) from 5-7, as usual. Thanks to Nandini, Caroline, Sherri, and Melissa for showing up. We took the wheels we are going to re-use off Rosie (last year's robot) and assembled the other wheels to be used for this year's robot. We also drilled more holes in the proto-type chassis. Yep, lots of hands-on work : ) Hooray!
Sunday, July 16, 2006
CalGames (October 27-28)
Dear gang,
Sorry I haven't had a chance to write back sooner!
It was really good to meet up at Google last Saturday with the CalGames folks from the Western Regional Robotics Forum (www.wrrf.org). Julia, just a warmning - the website sort of sucks. The information on it is outdated so I'll forward you information from Ceal Craig (one of the coordinators) after this email.
So, on the CalGames note, here are my thoughts:
I had lunch with Chrissy on Friday. She and I think it's going to take a lot of effort, and that we should make sure that we have a critical mass committed to doing this beforehand. This is not to be pessimistic or anything, but given that it is a volunteer-heavy event, if only like FIVE of us go, it's going to be painful. I *really* don't like it when someone commits me to doing / supporting something people don't pull through.
Kersten, I TOTALLY agree with you on the volunteering hours / community work thing. We can certainly recruit a lot of Casti students to come and the community hours thing is an incentive. Does the October 27-28 dates conflict with any school events?
On that note, I believe there is another option - if we DON'T want to enter as a team for the $600 entrance fee, there's nothing that says that we can't bring a gang of volunteers and new robotics rookies to HELP OUT! This would be low key, no prep in advance, and really great for exposing new students what a robotics competition is like, and of course, give them community service hours.
So here are my goals:
1. Bring at least 10 students to CalGames, of which at least 5 are new students. This is a great opportunity to expose newbies!
2. If we are serious about entering the competition, we should be serious about attempting to do well. I am not comfortable bringing new students to the competition and putting them at the wheel without at least attempting to leverage this opportunity to repair Rosie. I *do not* a new student's first experience with robotics to be a stressful one, where they watch us scramble before each match to make a new PVC chain tensioner. I just can't see myself being there watching that happen again.
If we don't have time to spend taking this competition seriously, we should considering going the less stressful route of putting our hearts into VOLUNTEERING FOR IT. I am not going to do anything half way.
3. Here are some realistic things that we can do to leverage this as a learning opportunity. Deadlines are GREAT for getting us to learn and getting us to do stuff during the off season.
* Build a new chassis. Kersten's learning to weld, and Julia is learning to put together weldment drawings in Solidworks. Chrissy has an Aluminum REM trip in the works. If we set aside some time and commit to this, I will do my part and convince Jimmy to give up a Saturday to work with you to design and weld an aluminum frame. This can be your test run before the US FIRST season. (Kersten, you'll discover that welding steel is a cinch, but aluminum is a whole another world that takes like years to learn)
* Improve the autonomous code and sensor / actuator systems. I'll work with Erin and Alecia to do this but this means we actually need a working robot that uh, drives straight when we ask it to.
My goal is help get people excited and bring people up to speed during the off season. CalGames can be the catalyst for that, but it doesn't need to be. Does that make sense? If CalGames takes all the wind out of me to coordinate and make happen, which means I have less time to teach people how to program, how to do electric stuff, gather materials and set up for the 2007, I would not be comfortable signing up.
Yeah.
Signing out,
Em
Sorry I haven't had a chance to write back sooner!
It was really good to meet up at Google last Saturday with the CalGames folks from the Western Regional Robotics Forum (www.wrrf.org). Julia, just a warmning - the website sort of sucks. The information on it is outdated so I'll forward you information from Ceal Craig (one of the coordinators) after this email.
So, on the CalGames note, here are my thoughts:
I had lunch with Chrissy on Friday. She and I think it's going to take a lot of effort, and that we should make sure that we have a critical mass committed to doing this beforehand. This is not to be pessimistic or anything, but given that it is a volunteer-heavy event, if only like FIVE of us go, it's going to be painful. I *really* don't like it when someone commits me to doing / supporting something people don't pull through.
Kersten, I TOTALLY agree with you on the volunteering hours / community work thing. We can certainly recruit a lot of Casti students to come and the community hours thing is an incentive. Does the October 27-28 dates conflict with any school events?
On that note, I believe there is another option - if we DON'T want to enter as a team for the $600 entrance fee, there's nothing that says that we can't bring a gang of volunteers and new robotics rookies to HELP OUT! This would be low key, no prep in advance, and really great for exposing new students what a robotics competition is like, and of course, give them community service hours.
So here are my goals:
1. Bring at least 10 students to CalGames, of which at least 5 are new students. This is a great opportunity to expose newbies!
2. If we are serious about entering the competition, we should be serious about attempting to do well. I am not comfortable bringing new students to the competition and putting them at the wheel without at least attempting to leverage this opportunity to repair Rosie. I *do not* a new student's first experience with robotics to be a stressful one, where they watch us scramble before each match to make a new PVC chain tensioner. I just can't see myself being there watching that happen again.
If we don't have time to spend taking this competition seriously, we should considering going the less stressful route of putting our hearts into VOLUNTEERING FOR IT. I am not going to do anything half way.
3. Here are some realistic things that we can do to leverage this as a learning opportunity. Deadlines are GREAT for getting us to learn and getting us to do stuff during the off season.
* Build a new chassis. Kersten's learning to weld, and Julia is learning to put together weldment drawings in Solidworks. Chrissy has an Aluminum REM trip in the works. If we set aside some time and commit to this, I will do my part and convince Jimmy to give up a Saturday to work with you to design and weld an aluminum frame. This can be your test run before the US FIRST season. (Kersten, you'll discover that welding steel is a cinch, but aluminum is a whole another world that takes like years to learn)
* Improve the autonomous code and sensor / actuator systems. I'll work with Erin and Alecia to do this but this means we actually need a working robot that uh, drives straight when we ask it to.
My goal is help get people excited and bring people up to speed during the off season. CalGames can be the catalyst for that, but it doesn't need to be. Does that make sense? If CalGames takes all the wind out of me to coordinate and make happen, which means I have less time to teach people how to program, how to do electric stuff, gather materials and set up for the 2007, I would not be comfortable signing up.
Yeah.
Signing out,
Em
Monday, June 19, 2006
The Shop
I don't know if anyone is actually reading this right now, but if you are:
What do you think of putting some shelving in the shop? Like, some actual robotics shelving, it might just be a shelf under the table in the back, but we could put, for example, the stuff currently in the corner of the project room down there and free up some space. I think it would be fine down there, we'd just have to make it clear that other people shouldn't touch it.
If there's no room for actual shelving, we might just clear a shelf on that rack by the back door and mark it "Robotics," put the long pieces up there, and store the smaller stuff under the table.
Kersten
What do you think of putting some shelving in the shop? Like, some actual robotics shelving, it might just be a shelf under the table in the back, but we could put, for example, the stuff currently in the corner of the project room down there and free up some space. I think it would be fine down there, we'd just have to make it clear that other people shouldn't touch it.
If there's no room for actual shelving, we might just clear a shelf on that rack by the back door and mark it "Robotics," put the long pieces up there, and store the smaller stuff under the table.
Kersten
Sunday, April 23, 2006
Maker Faire Blog Entry
Check out my blog entry on our trip to the Maker Faire here: Maker Faire Blog
Who was there? Kersten, George, Beth, Em, Eric, Debbie, Ryan, Ryan's friend, and possibly Chrissy and Heidi on Sunday?
This lightbulb / egg plotter is one of many cool things we saw!

Who was there? Kersten, George, Beth, Em, Eric, Debbie, Ryan, Ryan's friend, and possibly Chrissy and Heidi on Sunday?
This lightbulb / egg plotter is one of many cool things we saw!
Monday, April 17, 2006
Where are our bumpers?
Does anyone know?
They're the green ones. They're kindof important. We kindof need them in order to make new and better ones. Yeah. Get back to me on this.
ps- kudos to you who are reading the blog.
They're the green ones. They're kindof important. We kindof need them in order to make new and better ones. Yeah. Get back to me on this.
ps- kudos to you who are reading the blog.
Sunday, April 16, 2006
general update: packing (oh boy!)
-we're taking our big metal shelving unit (yes, we found the black plastic pieces)
-we've put together three wheels from IFI robotics and they're a tiny bit lighter than our old wheels!!!
-chrissy and sophia will make bumpers
-i think we're meeting everyday this week (mon-fri) after school until about 4:30 or 4:45 (as usual).
-kersten essentially declared herself our resident packing expert, so chrissy and i have decided to let her do everything (ha ha!)
-we've put together three wheels from IFI robotics and they're a tiny bit lighter than our old wheels!!!
-chrissy and sophia will make bumpers
-i think we're meeting everyday this week (mon-fri) after school until about 4:30 or 4:45 (as usual).
-kersten essentially declared herself our resident packing expert, so chrissy and i have decided to let her do everything (ha ha!)
Friday, April 14, 2006
boxes
so you know the two semi-translucent boxes with screws and bolts and such in them- one labelled machine screws, the other wood screws? I think we took them to SVR, but I'm pretty sure they weren't at Portland, and I'm wondering if we actually need them. Does anyone have a reason for why we should take them? Because they're heavy and we already have most (if not all) of the stuff we know we need in other boxes.
Also, I'm thinking we just wrap a lot of tape around the boxes to keep them from coming open (in addition to using the little holes for zip tying them closed), but does anyone have doubts about that? Because I can try to contact 114 and ask how they secured their stuff to Portland in the boxes, cuz that seemed to work.
We've got two boxes packed and (according to J Rock's unreliable scales) under the 50 (or is it 55?) lb weight limit, and looks like we can fit the rest of the stuff in the remaining three boxes fine. I hope nobody minds that we have some chunks of noodle in the bins, because we're too cheap to get actual bubble wrap. Since most of the stuff from the bins will be moved to the shelves, I figure storage for the noodles shouldn't be a problem in the pit.
If anyone is reading this, how about you give me a call and tell me if you can meet on Sunday (bear in mind that it's Easter for some of you). I think I might be able to, if I get my homework done.
Kudos to all the people who did cool stuff over break.
Kersten
Also, I'm thinking we just wrap a lot of tape around the boxes to keep them from coming open (in addition to using the little holes for zip tying them closed), but does anyone have doubts about that? Because I can try to contact 114 and ask how they secured their stuff to Portland in the boxes, cuz that seemed to work.
We've got two boxes packed and (according to J Rock's unreliable scales) under the 50 (or is it 55?) lb weight limit, and looks like we can fit the rest of the stuff in the remaining three boxes fine. I hope nobody minds that we have some chunks of noodle in the bins, because we're too cheap to get actual bubble wrap. Since most of the stuff from the bins will be moved to the shelves, I figure storage for the noodles shouldn't be a problem in the pit.
If anyone is reading this, how about you give me a call and tell me if you can meet on Sunday (bear in mind that it's Easter for some of you). I think I might be able to, if I get my homework done.
Kudos to all the people who did cool stuff over break.
Kersten
Tuesday, March 28, 2006
Because 18 comments doesn't need one more
Hey! Has anyone by any chance seen the black pieces to hold up those nice, shiny, metal shelves? Also, have you guys seen any loose allenwrenches anywhere?
Thanks!
-the Dungeon Master
P.S. Yeah, I know I sent most people an email about this, but a U.R.L. told me to blog it as well.
Thanks!
-the Dungeon Master
P.S. Yeah, I know I sent most people an email about this, but a U.R.L. told me to blog it as well.
Sunday, March 19, 2006
Atlanta
So the championship is april 27-29.
I was just thinking about stuff we need to get done (because you guys wouldn't let me start a list last night), and here's a preliminary list:
-pack tools and parts
-buy parts (like more zip ties. Unless we still have the billions that people gave to us)
-make a mobile pit, which we will actually need in Atlanta
-take more batteries
-repair our current bumpers
-make more bumpers (preferably better designed...)
-figure out how to attach bumpers (preferably some method that does not require zip ties, cool as they are)
-figure out how to tension our chain (also preferably some method that does not involve zip ties, because it means replacing them after every round)
-figure out what to do about our HUGE chassis rail bending/crooked wheel problem. We now only have two chassis rails that we can use from Thor, and as we now know, just replacing the ones on Rosie doesn't actually work. Unless maybe we try replacing the inside ones.....? We can discuss this.
-wash our gatorbotics shirts, because I'm sure they all smell.
-What else?
Yay, everybody, we're going to Nationals!!!!!!!!
Kersten
I was just thinking about stuff we need to get done (because you guys wouldn't let me start a list last night), and here's a preliminary list:
-pack tools and parts
-buy parts (like more zip ties. Unless we still have the billions that people gave to us)
-make a mobile pit, which we will actually need in Atlanta
-take more batteries
-repair our current bumpers
-make more bumpers (preferably better designed...)
-figure out how to attach bumpers (preferably some method that does not require zip ties, cool as they are)
-figure out how to tension our chain (also preferably some method that does not involve zip ties, because it means replacing them after every round)
-figure out what to do about our HUGE chassis rail bending/crooked wheel problem. We now only have two chassis rails that we can use from Thor, and as we now know, just replacing the ones on Rosie doesn't actually work. Unless maybe we try replacing the inside ones.....? We can discuss this.
-wash our gatorbotics shirts, because I'm sure they all smell.
-What else?
Yay, everybody, we're going to Nationals!!!!!!!!
Kersten
Friday, March 10, 2006
CG
Anyone who is thinking about how we might lower our CG:
Kersten's mother kindly reminded us that we can add 15lbs in bumpers to the base of our robot...!
Kersten's mother kindly reminded us that we can add 15lbs in bumpers to the base of our robot...!
Thursday, March 09, 2006
List from Chrissy/Kersten
To do before SVR:
-Make bumpers (Saturday, time TBD)
-Figure out if/how we're going to remodel our robot
-Tell people to bring the goggles they were given
-Advertise SVR to school
-Figure out what's going on each shelf
-Label shelves
-Velcro a power strip to shelf
-Take apart shelves
-Colaborate with the electronics team (what needs to be brought?)
-Put black shelves in car, to bring into pit only if necessary
To buy before SVR:
-green electrical tape
-black electrical tape
-bungy chords
-red locktite
-blue locktite
-Make bumpers (Saturday, time TBD)
-Figure out if/how we're going to remodel our robot
-Tell people to bring the goggles they were given
-Advertise SVR to school
-Figure out what's going on each shelf
-Label shelves
-Velcro a power strip to shelf
-Take apart shelves
-Colaborate with the electronics team (what needs to be brought?)
-Put black shelves in car, to bring into pit only if necessary
To buy before SVR:
-green electrical tape
-black electrical tape
-bungy chords
-red locktite
-blue locktite
Tuesday, March 07, 2006
Tuesday
Hey guys!
So if you take a look at the project room, well, it's an organized mess. We unpacked everything and had to go before we could relocate most of it into the boxes or tool chests. On the plus side, though, we have a mostly comprehensive first draft of a packing list of stuff to take to SVR (having inventoried what we unpacked from Portland). We also learned some more about shipping heavy things in plastic containers. What a 'learning experience' this has been. Yay.
See everyone tomorrow at the lunch meeting!
Kersten
So if you take a look at the project room, well, it's an organized mess. We unpacked everything and had to go before we could relocate most of it into the boxes or tool chests. On the plus side, though, we have a mostly comprehensive first draft of a packing list of stuff to take to SVR (having inventoried what we unpacked from Portland). We also learned some more about shipping heavy things in plastic containers. What a 'learning experience' this has been. Yay.
See everyone tomorrow at the lunch meeting!
Kersten
Monday, March 06, 2006
not finished yet...
hookay, so...
PLEASE COME HELP KERSTENS MOM UNPACK TODAY! SHE IS COMING AT 3:30 AND NEEDS HELP MOVING BUNCHES OF SUITCASES UP THE STAIRS AND UNPACKING THEM
THANK YOU!
PLEASE COME HELP KERSTENS MOM UNPACK TODAY! SHE IS COMING AT 3:30 AND NEEDS HELP MOVING BUNCHES OF SUITCASES UP THE STAIRS AND UNPACKING THEM
THANK YOU!
Sunday, March 05, 2006
Portland regionals
Without help from our mentors for the first two days, we successfully managed to repair all problems that came up including the chain falling off and turret comming loose. Thank you to all our wonderful mentors who taught us the skills to be able to fix these daunting problems!
Wednesday, February 22, 2006
Acidicly, we ROCK!!!!!!!!!!!!!!!!!!!!!!!!!!!!!!!!!!!
i would just like to offer up thanks to everyone who helped us...yay!!!
kersten? is the digging machine party on? who do i talk to about that?
BUILD_ WE ARE NOT FINISHED, THIS WEEK WE NEED TO MAKE THE BUMPERS AND GET TOGETHER WHAT WE ARE GOING TO TAKE WITH US TO PORTLAND. AND NO, WE CANT TAKE EVERYTHING. WHEN WOULD PEOPLE LIKE TO MEET THIS WEEK? PERHAPS FRIDAY OR SATURDAY? OR IF WE END UP HAVING A PARTY, THAT COULD POSSIBLY INCLUED THE MAKING OF BUMPERS, (WHICH ARE NOT THAT COMPLICATED TO MAKE)
ON THAT SAME NOTE, DOES ANYONE HAVE 6 POOL NOODLES THAT WE COULD HAVE?
kersten? is the digging machine party on? who do i talk to about that?
BUILD_ WE ARE NOT FINISHED, THIS WEEK WE NEED TO MAKE THE BUMPERS AND GET TOGETHER WHAT WE ARE GOING TO TAKE WITH US TO PORTLAND. AND NO, WE CANT TAKE EVERYTHING. WHEN WOULD PEOPLE LIKE TO MEET THIS WEEK? PERHAPS FRIDAY OR SATURDAY? OR IF WE END UP HAVING A PARTY, THAT COULD POSSIBLY INCLUED THE MAKING OF BUMPERS, (WHICH ARE NOT THAT COMPLICATED TO MAKE)
ON THAT SAME NOTE, DOES ANYONE HAVE 6 POOL NOODLES THAT WE COULD HAVE?


Sunday, February 19, 2006
Under the hood

Sophia, under the hood, re-soldering the connections to the potentiometer - worth its price in gold to see. Today has been a really amazing day. We spent the better part of the morning until early evening at IDEO and a certain office van dweller named Sven helped us transport Rosie back to Castilleja.
I'm overwhelmed and amazed by the generosity of so many people - Jim Feuhrer for stepping up this week pulling through a full seven days of midnight departures to build the hopper and the ramp, rebuild the turret plate, and mount multiple sensors, George Schnurle for coming by to give moral support and good humor even though his daughter is 3000 miles away, Doug Bourn for somehow managing to find time to come by even though he is up against an even tighter and tougher deadline at Tesla Motors, Eric Macintosh for some serious coding prowress, Bud Delisle for being there for the girls, Chris Countryman for animation advice and helping me in my braindead state to implement an RC switch debounce, George Aye for coming ALL the way from Chicago to offer his rendering expertise to Shirin, Beth Schnurle, Debbie Hara, and Heidi Crone for their undying wisdom, encouragement and support, and of course, David Berger for the famous quiche that keeps me coming back for more.
The Castilleja gymnasium is officially taken over by robotics for the next 48 hours. I think Rosie can go up against any basketball player. The kiddos brought a couch into the gym - they are all becoming serious couch potato roboticists.
This is a huge accomplishment for the team this year. We went from Thor, a robot with five motors and no sensors and no autonomous code last year to Rosie, a robot that has eight motors, three complicated sensors with interrupt code, and some sort of autonomous behavior to be yet determined. Still going with another 60 hours left. I'm really amazed that this team pulled it off. Even if Rosie is still in its infancy in terms of intelligence, she'll do some serious damage on the field . . . . ;)
Thursday, February 16, 2006
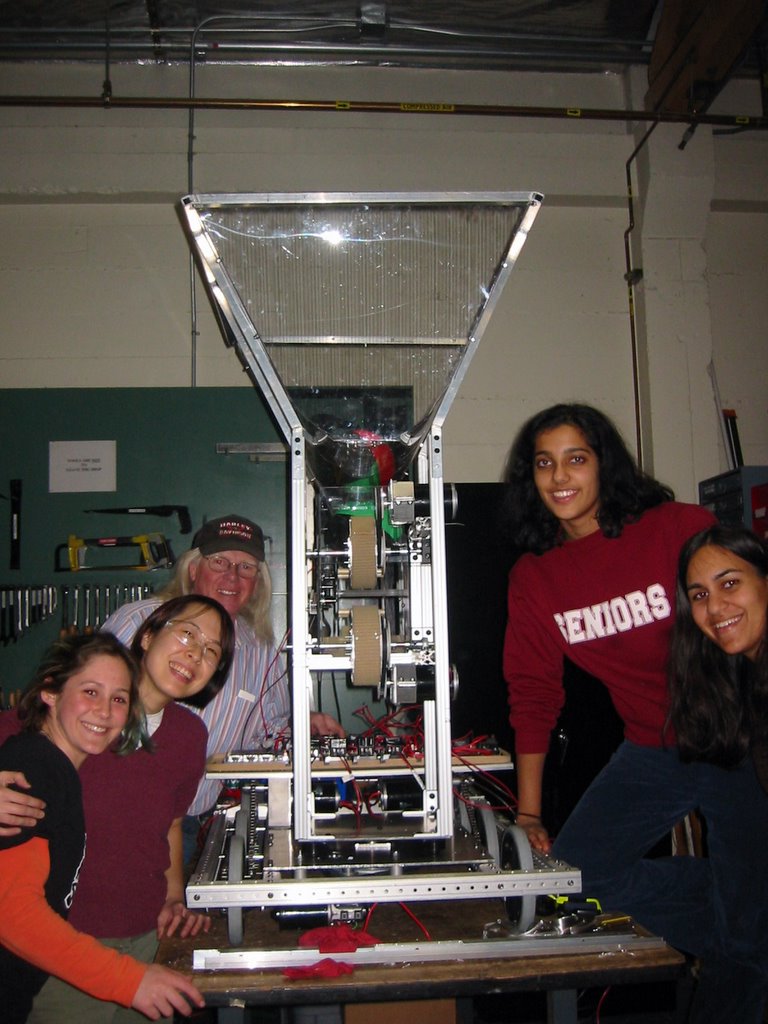
Extreme weight loss program worked! Jimmy and Bud and the gang took out all sorts of stuff - motor sprocket got taken down to half the weight, all the dead weight was removed, the transmissions were pulled out and the gears were pocketed, the 80-20 frame struts were removed (and still quite stable), the metal plate underneath the electronics box was cut down, the chain tensioners replaced by half links, chester turned into a leaner meaner metal plate . . . that's an entire 20 lbs gone!
9:30 pm Chrissy and I hooked both the launching motors and the gate motor up to a battery and successfully launched two balls in succession. Definitely a jumping up and down moment!!
One ounce at a time.
Jimmy and Bud can't help themselves. Both lathes whirring, 1 ounce at a time, they are determined to get the robot in shape. Everything that can be turned down in diameter is getting turned down . . . sprockets, gears, everthing.
20 lbs = 320 ounces. One ounce at a time.
Not my idea, but I was working on the mill and it was really a kodak moment see both Jimmy and Bud work on the lathe at the same time for the same cause. The two of them are on a crusade now.
20 lbs = 320 ounces. One ounce at a time.
Not my idea, but I was working on the mill and it was really a kodak moment see both Jimmy and Bud work on the lathe at the same time for the same cause. The two of them are on a crusade now.
Wednesday, February 15, 2006
24 hour Hollywood Diet
our robot is fat
i'm thinking south beach, or maybe slim-fast, 24 hour hollywood diet, perhaps the grapefruit or juicing diet, atkins, low-carb, low-fat, low-calorie, low sugar diet?
think light thoughts
think helium
think how we can lose 20 pounds
we'll make a fortune, "lose 20 pounds in under a week!"
for referance, 20 pounds is 2 batteries.
what could we cut holes in? what can we remove? what can we do without?
sleep on it, keep it in the back of your mind, and tomorrow we'll get something done.
i'm thinking south beach, or maybe slim-fast, 24 hour hollywood diet, perhaps the grapefruit or juicing diet, atkins, low-carb, low-fat, low-calorie, low sugar diet?
think light thoughts
think helium
think how we can lose 20 pounds
we'll make a fortune, "lose 20 pounds in under a week!"
for referance, 20 pounds is 2 batteries.
what could we cut holes in? what can we remove? what can we do without?
sleep on it, keep it in the back of your mind, and tomorrow we'll get something done.
Tuesday, February 14, 2006
IDEO 11:30 pm Valentines Day
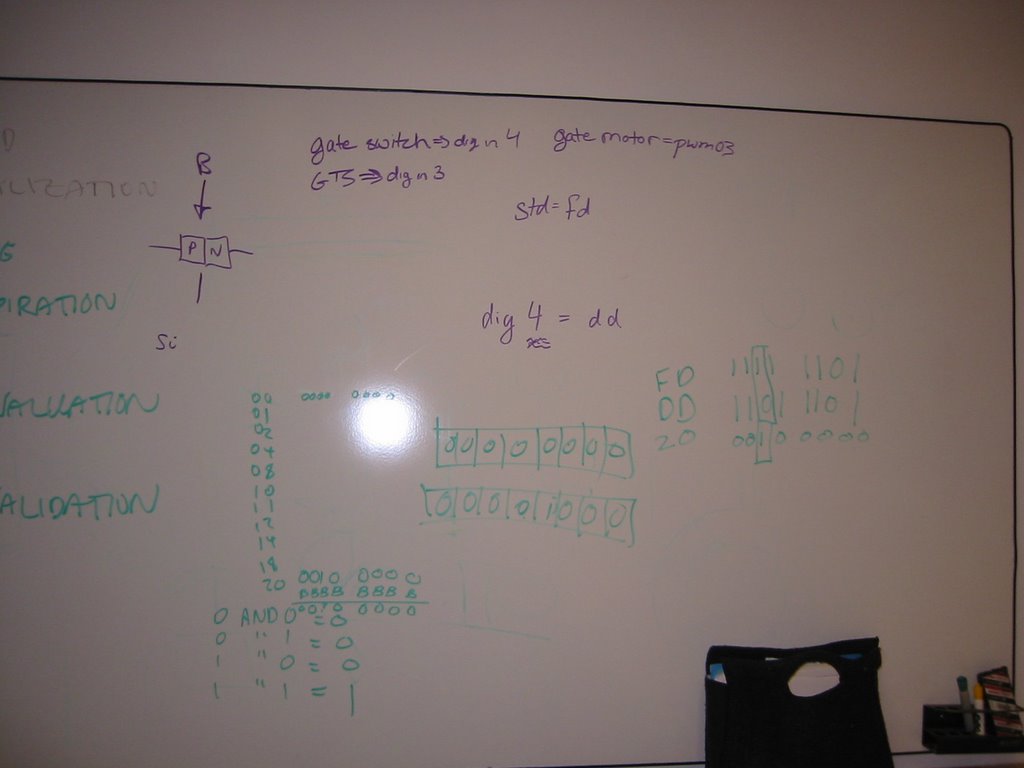
Jimmy just went home. Just wanted to post these two important photographs.
1. Jimmy, in all his kindness and generosity, couldn't put up with a direct drive motor, so after a quick mad race to find v-belt pulleys and a v-belt, we had something running by 11 pm tonight at IDEO. It is geared down by a factor of four, which means when you run the motor at maximum efficiency right now (approximately 6v), you get a really beautiful smooth motion.
2. We had to clean up the shop. It is becoming a bit of a problem here with the amount of room we are taking up. I also erased everything off the whiteboard so I've attached a photograph for programming above, just in case you need your pinout information. Eric McIntosh and Doug have been a great help getting the indexing system working with the interrupt.
It's been a tough tough week. Remember that although you can stay up late and have fun in your teens, us old and crotchety mentors don't last too many 11 pm days in a row.
I am going home now so I can sort of do my part on my real job.
- Emily
I love you all
Regardless of how things turn out, and how robotics goes, I want to let you know, especially on this special day, that you are all fantastic individuals. It has been my privilege and honor to get to know you. Working in teams is a really really hard thing - there are multiple areas of academia that study teamwork alone. Sometimes it is really hard to work with our best friends. Sometimes our best workmates are not our best playmates. Working together requires a very different type of respect for each other than playing together. When you are on a team, like a soccer team, you want to know that when you kick the ball to someone, that they will be there for you to receive your ball. You kick the ball to people who you know will move your team towards the goal. Sometimes, your best friend isn't the best person to kick the ball to even though you can count on her to help mend your broken heart or cheer you up on a cloudy day.
To this day, I remember and regret losing a few great friendships because we didn't get along as a team on a project. It takes maturity and openmindedness to look beyond a tough and challenging experience to maintain a friendship through the trials and tribulations of team work.
In the end, even if we don't have a robot that is working, we have a friendship that we can cherish. Happy Valentines Day Gatorbotics!
To this day, I remember and regret losing a few great friendships because we didn't get along as a team on a project. It takes maturity and openmindedness to look beyond a tough and challenging experience to maintain a friendship through the trials and tribulations of team work.
In the end, even if we don't have a robot that is working, we have a friendship that we can cherish. Happy Valentines Day Gatorbotics!
A plea from programing
We need to get sensors up and runing as fast as possible. Programing has done their part: The code is mostly up and running. Unfortunately, before they can debug they need a platform to run things on. If you have any hope of autonomous, you need to get the GTS mounted. I know this is no easy task (it needs to be under 1.5-2mm from the gear, but please, don't let all the wonderful coding go to waste. Also, if you have anything else you want programmed, you need to let programing know ASAP.
Thanks!
Thanks!
HAPPY VALENTINE'S DAY!
we should kick some butt today...let's get something that fits together today...i believe in us..
Monday, February 13, 2006
Moon Monday
Here are some happy pictures from this evening. I posteth them before I head to homework...and then bed. Enjoy!


Yeah...there was a fourth...but I dubbed it the "Evil Glare of Julia" and chose not to post it for fear of being beheaded.
-Alecia

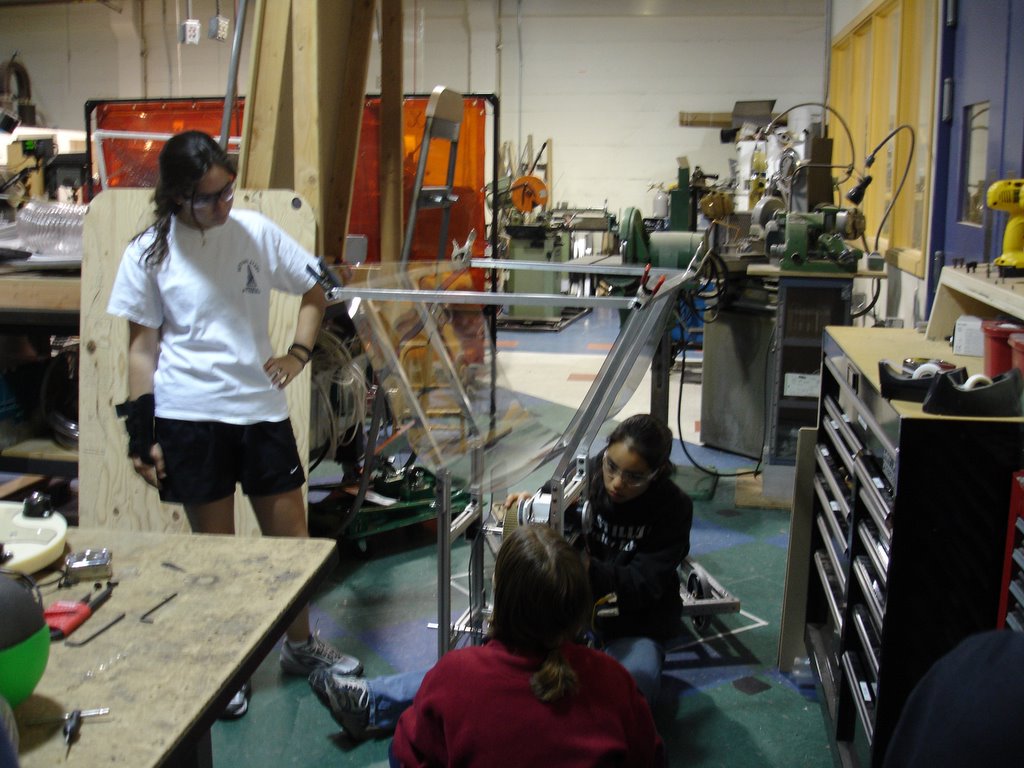
Yeah...there was a fourth...but I dubbed it the "Evil Glare of Julia" and chose not to post it for fear of being beheaded.
-Alecia
Sunday, February 12, 2006
Sooooper Sunday
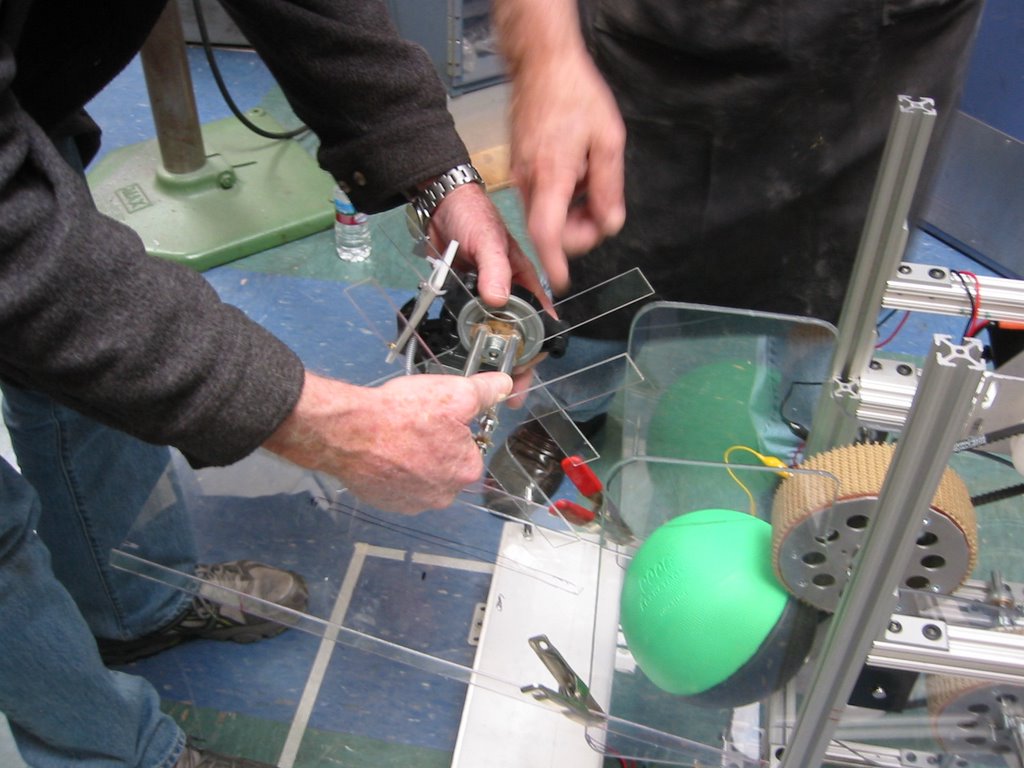
Bud, Jimmy, Kersten, Chrissy, Beth, Heidi and I got cranking this Sunday afternoon. Jimmy, especially, came in our hour of need and helped us think out of the box - literally. I had a lot of reservations about fixing the hopper to the chassis and have the turret rotate, given that we'd have a ramp cantilevered off the turret, and then Jimmy took a look at it and asked, can't we fix the hopper to the top of the turret as well? So given that we can expand to 60" by 60" once we start, having a 28" X 38" hopper that rotates is NO PROBLEM now.
As well, Jimmy WELDED a beautiful and light 3 lb. hopper frame for us. Now its all Chrissy's and Kersten's to add mesh and polycarb sheeting to.
We also did a bunch of brainstorming on the indexing / gating device. Instead of having the ramp come in from the side, the hopper allows the balls to come in from the top now, and we can float the gating device rather than have to cut slots in the ramp. More coming tomorrow. We're getting there.
One thing that was really useful for me today was to kind of mock everything up in terms of the launching sequence. With a bunch of things clamped to the launcher, and everyone helping ou and holding something, whether it was the gating device, or the ramp, we tried loading two balls down the hopper, and hooking up the gating device temporarily so it would turn and load balls one at a time. Man, that really helped solidify things for me.
Kudos to Chrissy and Kersten for the good work today prototyping the hopper with the mesh stuff. Lots of good prototyping and learning going on today that made it really fun!!!
TOMORROW. 5:30 pm. IDEO. BRING CHASSIS AS WELL.
Bud and I are both worried that with all the stuff on top of it, the launcher is going to bounce itself off the chassis and run away!!! See you later!!
The movie thing
Hey, guys!
So I think you guys told me what was going on in the movie and I couldn't remember if there was any Gracious Professionalism in it. I think including GP would be good if you can. Probably we don't want to buy gracious proffessionalism in the hardware store, cuz then it doesn't seem like we had it last year, but maybe if we buy a GP, like, refill or something? Or have a vat of it in the van that you can see from outside? I dunno. And if you already have it worked in somehow, that's awesome and you can ignore this.
Cheers!
Kersten
So I think you guys told me what was going on in the movie and I couldn't remember if there was any Gracious Professionalism in it. I think including GP would be good if you can. Probably we don't want to buy gracious proffessionalism in the hardware store, cuz then it doesn't seem like we had it last year, but maybe if we buy a GP, like, refill or something? Or have a vat of it in the van that you can see from outside? I dunno. And if you already have it worked in somehow, that's awesome and you can ignore this.
Cheers!
Kersten
SUNDAY 1:20 at IDEO SHOP
definitly coming in tomorrow ( AT THE IDEO SHOP) at 1:30...we have
demsions for where the ramp needs to go, along with angle and where it's going to be mounted. Bud made us sweet guides taht attach to the motor shaft so the thing stays square as a plus. aslo it isn't vibrating as much, so good. kersten had a good idea to mount t pieces of something as a ramp, so the ball would have to travel down the predetermined lane. we still need to decide where the window motor is going to be mounted. my mother and i got started watching the olympics and suddenly it's late, so we wont be prototying tonight...sorry :( but we got this KICK ASS netting stuff at home depot. it's for putting over plants and such so birds/dear don't eat them. it's really STRONG and WAY LIGHTER than the shower curtain...i'm also thinking it will be easier to mount (zip ties) and we got a roll 7' by 100' for $15, so i think that's a pretty good deal... :) it also looks WAY easier to mount. think seran wrap over a plate(i know it's spelled wrong and i dont care) we can take one sheet and lay it crosswise over another one, and then just cut a hole in the bottom. let's get to it!!!!!!!! we can finish this thing tomorrow...
demsions for where the ramp needs to go, along with angle and where it's going to be mounted. Bud made us sweet guides taht attach to the motor shaft so the thing stays square as a plus. aslo it isn't vibrating as much, so good. kersten had a good idea to mount t pieces of something as a ramp, so the ball would have to travel down the predetermined lane. we still need to decide where the window motor is going to be mounted. my mother and i got started watching the olympics and suddenly it's late, so we wont be prototying tonight...sorry :( but we got this KICK ASS netting stuff at home depot. it's for putting over plants and such so birds/dear don't eat them. it's really STRONG and WAY LIGHTER than the shower curtain...i'm also thinking it will be easier to mount (zip ties) and we got a roll 7' by 100' for $15, so i think that's a pretty good deal... :) it also looks WAY easier to mount. think seran wrap over a plate(i know it's spelled wrong and i dont care) we can take one sheet and lay it crosswise over another one, and then just cut a hole in the bottom. let's get to it!!!!!!!! we can finish this thing tomorrow...
Saturday, February 11, 2006
We created . . . a Mmmmonster!!
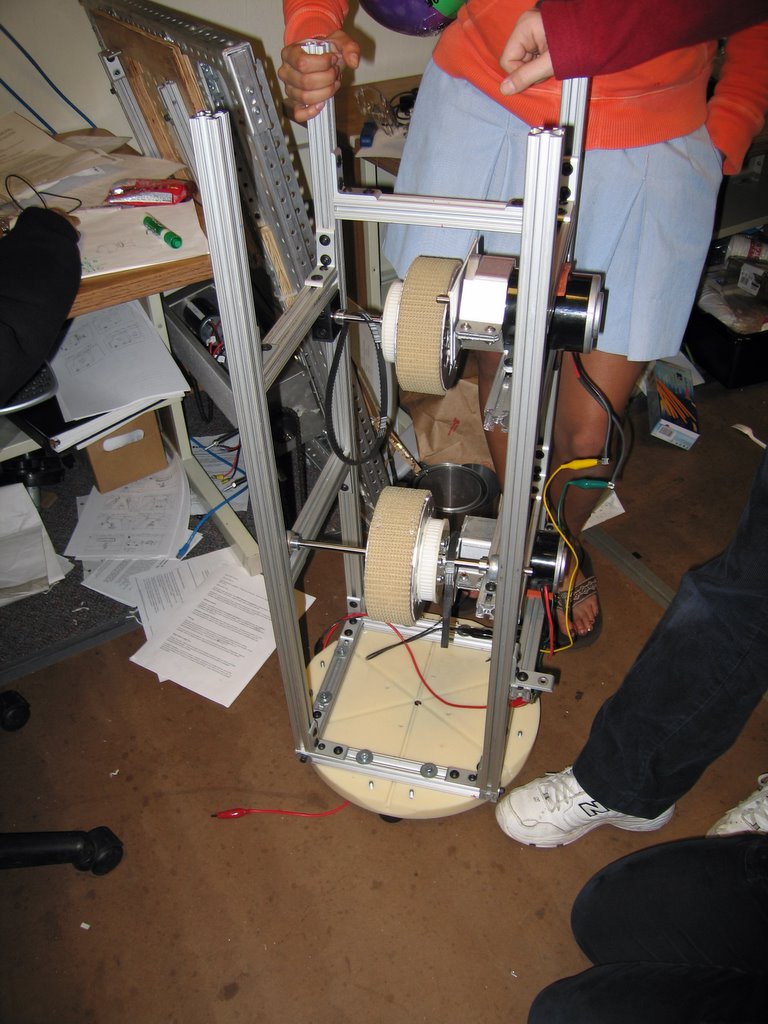
Named CHESTER!!
It also shoots like, um, a little to far now. Like across the field and 20 ft high, so we'll need to reduce / adjust the speed in software. I'm scared of this thing. I definitely don't want to be standing in front of it. We were hitting windows on on the second story in the IDEO alley way. We almost accidentally launched the ball onto the roof of the shop as well. Very scary.
Some issues we are dealing with:
- Structure seems to want to vibrate itself apart when the launcher is running (scary!!)
- No guides on the side, so sometimes the ball gets randomly sucked in sideways, resulting in shooting off to one corner. We definitely need to work on repeatability and accuracy a little bit more.
- Ramp? How are we going to secure the gate? So many things!!
Someone update me!!! What did Bud and you guys do after Kersten and I left for the rest of the afternoon?
Em
Backbot clarification
Kersten asked about this earlier, so I just want to clarify. The "Backbot" is from the defending alliance. During the middle two periods, there are three offensive robots and two defensive robots. Thus, advantage goes to offense. Note the fact that this means that the defense cannot be guarding both low goals and messing with the shooter.
Quick Updates: Progress
So we haven't checked in here for a while, but we're definitely making progress. A little scary with so many days left, but we're making our way there.
OVERALL WEIGHT:
Not to overly worry about it yet, but we're definitely getting to the heavy side. We're sitting at 100 lbs - the chassis at 70 lbs and the turret frame structure at 33 lbs. This means we need to get EVERYTHING else in under 20 lb. Not impossible but definitely a little disconcerting.
TURRET:
Build team mounted the frame to the turret base with the casters on it. Looks pretty good. It's kind of cute actually, like a little deadly R2D2. How is programming doing with limiting the range - alas, I am worried about programming. Setting up the code and sensors to do this kind of thing doesn't just come together like in a day . . . and it needs to be fault proof or else our electronics board is getting it because that van door motor will stop at nothing!!
LAUNCHER:
Okay, we're at 33lbs. One way to get rid of the weight is to remove the entire yellow base all together. Seriously, because you have the square at the bottom holding your frame together, why not just bolt your casters to that and modify the motor shaft adapter to be a lot lighter?
We have all the parts needed for a 1:1 gear ratio now for the launcher. Both are 2.75" diameter pulleys. I also have a huge assortment of timing belts now just in case we run into some issues getting everything in the frame.
HOPPER:
With Chrissy and Kersten on it, we should be done in no time. Like finish TODAY. This is SATURDAY.
GATE AND RAMP:
Needs work. Sophia, Erin and I did a little b-storming and put together a little prototype. Now we need to figure out how to mount the motor to the ramp and how to stabilitze the structure of the ramp itself. Crazy stuff. Perhaps that 'flag post' we'll have at the back of the robot will be good to mount the ramp to.
OTHER STUFF: Is anyone thinking about this stuff?
- electronics cover
- PVC flag post (to display your alliance color)
- All your signage
- All your bumpers
Okay, signing out,
Em
OVERALL WEIGHT:
Not to overly worry about it yet, but we're definitely getting to the heavy side. We're sitting at 100 lbs - the chassis at 70 lbs and the turret frame structure at 33 lbs. This means we need to get EVERYTHING else in under 20 lb. Not impossible but definitely a little disconcerting.
TURRET:
Build team mounted the frame to the turret base with the casters on it. Looks pretty good. It's kind of cute actually, like a little deadly R2D2. How is programming doing with limiting the range - alas, I am worried about programming. Setting up the code and sensors to do this kind of thing doesn't just come together like in a day . . . and it needs to be fault proof or else our electronics board is getting it because that van door motor will stop at nothing!!
LAUNCHER:
Okay, we're at 33lbs. One way to get rid of the weight is to remove the entire yellow base all together. Seriously, because you have the square at the bottom holding your frame together, why not just bolt your casters to that and modify the motor shaft adapter to be a lot lighter?
We have all the parts needed for a 1:1 gear ratio now for the launcher. Both are 2.75" diameter pulleys. I also have a huge assortment of timing belts now just in case we run into some issues getting everything in the frame.
HOPPER:
With Chrissy and Kersten on it, we should be done in no time. Like finish TODAY. This is SATURDAY.
GATE AND RAMP:
Needs work. Sophia, Erin and I did a little b-storming and put together a little prototype. Now we need to figure out how to mount the motor to the ramp and how to stabilitze the structure of the ramp itself. Crazy stuff. Perhaps that 'flag post' we'll have at the back of the robot will be good to mount the ramp to.
OTHER STUFF: Is anyone thinking about this stuff?
- electronics cover
- PVC flag post (to display your alliance color)
- All your signage
- All your bumpers
Okay, signing out,
Em
Friday, February 10, 2006
Wednesday, February 08, 2006
Warm thanks to Kersten, Beth and George
What a wonderful surprise at 9 am.
Bud, myself and the entire IDEO shop thank you dearly ;)
Tuesday, February 07, 2006
Things are not as easy as they seem
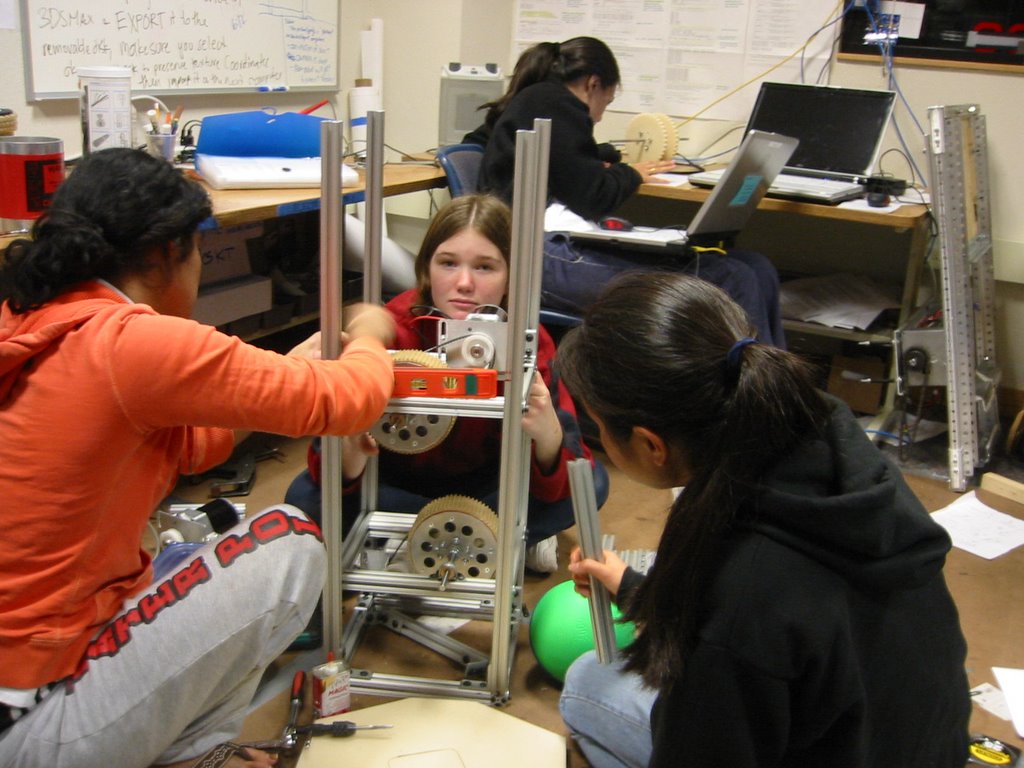
We're coming along, but it's hard with 13 days left to discover that there are a lot of little things that need to be though through. For me, time is the biggest priority right now - and that is why I am advising you with that in mind, going for concepts that are easier to successfully implement in the time that we have left, rather than trying out fancy things. If this does not jive with you, please let me know. Your priorities are the most important and all I can do is give you my best advice and support based on my experiences, and you can take it or leave it.
What's left to do? A lot of stuff!
LAUNCHER:
Kersten and Julia did some mulling over getting the 45 degree angle on the launcher and came up with a great idea of having the wheels not be right on top of each other. Fantastic! Unfortunately, we came up a little short - literally today. The frame being smaller, Emily will need to order new shorter timing belt pulleys on Wednesday for Thursday delivery. Yes, it will be another two days before you can get the launcher finished because once again, lest I remind you that parts require time to get shipped.
TURRET:
Aditi and Kersten put together a good plan for Bud to work on tomorrow, if he is free to do so. The plan was almost complete, and we talked about how a simple drawing with the hole patterns required to mount the frame as well as the casters would be useful since BUD is going to put the part on the CNC machine anyhow. I am going to stock the science project well from now on with graph paper. See my drawing below - you don't need CAD to covey to BUD or myself what you need done in the IDEO shop. (Kudos to Julia, who has already done this yesterday!)
GATE FOR BALLS:
Sophia, as much as I love your home made electromagnet, and as much as I appreciate you sharing those ideas with me, I have to admit your suggestion actually stressed me out a little bit. If this is your priority, please let us know and we'll focus on building an electromagnet, but I cannot ensure that we'll have something working for the gate by the end of this project. Again, I highly suggest choosing either the globe or denso motors, and just putting on a flag. Things take a LOT of time to calibrate. The build team hasn't really gotten to a point where they can understand how to structurally mount this motor so we're really waiting for them to reach that point as soon as possible.
BALL HOPPER / CATCHER:
Definitely needs some thinking. What is the plan here and how can we at IDEO help you out?
IN GENERAL:
With 13 days left, my realistic opinion is that we'll have a chassis that we can drive around and a turret that we can turn. The launcher, the ball hopper and the gate all still need to be integrated and I am not confident that this will happen in the time frame that we have.
At the core of this experience, it is my true pleasure to work with you, but I cannot help but to express my disappointment right now. You all had such high hopes at the beginning of the season and even with my hesitation, you managed to convince me that this was a path (shooting through the center goal. and getting the vision camera working) that we should take! This is no easy feat as I am not easily convinced. I am disappointed because of how things have come along, that we really aren't going to get to any of the autonomous stuff, nor the vision camera. That is fine, but I really wish you had told me not to spend the many hours I did already to understand the camera code, when we weren't going to really have a chance to use it at all. It's really frustrating being part of the programming team and not have anything to program or code when the hardware and the mechanical stuff isn't sorted out or even clearly conveyed to us. I will continue trying to be optimistic, but I am quickly running out of happy pills :(
A well planned engineering project and experience doesn't need to be like this. We don't need to stay up all night figuring things out. We don't need to work until the very last minute. Frankly, it would possibly be more useful to finish early and have the drivers get lots of practice with the robot. The truth is, as much as the rush of staying up all night in the very few last days, and as cool as we all think it might be, I don't think it's all that cool anymore. I wish we could work more efficiently and have clarity in what we do. Dang it, I want my 7 hours of sleep a night at my ripe old age of 24. I can't keep up with you anymore ;(
Monday, February 06, 2006
it's.....AAALLLLIIIIIVVVVVEEEEEEEE!
it moves around on the floor
got kick-ass prototype from em at ideo today
tapped holes, took stuff apart, put stuff together
(can you tell that i'm tired? :)
tomorrow
aditi and i are getting to the project room at 3 to start working on either the base of the turret or the launcher, wherever our creative genius takes us. when you show up, we will assign you to either the launcher (which shouldnt be that hard to put together) or the turret.
GOALS
finish launcher by TOMORROW(this should be easy, guys. we have all the parts, we have all the specs, we just need to assemble)
finish turret by FRIDAY because programming needs to start coding. this is important if we want an autonomous code.
ok, that is it. tired.
nighty night!
got kick-ass prototype from em at ideo today
tapped holes, took stuff apart, put stuff together
(can you tell that i'm tired? :)
tomorrow
aditi and i are getting to the project room at 3 to start working on either the base of the turret or the launcher, wherever our creative genius takes us. when you show up, we will assign you to either the launcher (which shouldnt be that hard to put together) or the turret.
GOALS
finish launcher by TOMORROW(this should be easy, guys. we have all the parts, we have all the specs, we just need to assemble)
finish turret by FRIDAY because programming needs to start coding. this is important if we want an autonomous code.
ok, that is it. tired.
nighty night!
Playing hookie at IDEO
 Around 11 am on Friday morning, Bud, Jimmy and I received a large box from Mcmaster and sort of stopped working all together on our real work. Kersten, Julia and Kersten's mom came to join us in the shop around 5 pm and we played around with different wheels, different amounts of squish, and vertical vs. horizontal
Anyhow, this is what came out of it. I'll post more on the process, and include a BOM (bill of materials) as well on how we put this together.
Check out the video: http://www.zippyvideos.com/4610912043602206/mvi_0653
Friday
[So weird - Kersten wrote this on Saturday morning, but it got erased :( . . . I copy and pasted her original post off of Google's cache]
OK, so I guess we kindof didn't meet on Friday, but Em invited the non-FOMF working people (aka me and julia) to ideo to play with this awesome little wheel prototype thing. I'm thinking we should try to get two wheels, because it works well, both vertically and horizontally. We can talk about it later once everyone has seen the prototype.Have fun FOMFing!And be sure to come to the SJ library, because that's the happenin' spot, you know.Kersten
posted by Kersten Schnurle at 8:06 AM
OK, so I guess we kindof didn't meet on Friday, but Em invited the non-FOMF working people (aka me and julia) to ideo to play with this awesome little wheel prototype thing. I'm thinking we should try to get two wheels, because it works well, both vertically and horizontally. We can talk about it later once everyone has seen the prototype.Have fun FOMFing!And be sure to come to the SJ library, because that's the happenin' spot, you know.Kersten
posted by Kersten Schnurle at 8:06 AM
Thursday, February 02, 2006
BAD-ASS
Ok so WE OFFICIALLY HAVE A ROBOT THAT RUNS! YAY!!!
so even if we cant do anything else, we can ram people. :)
but seriously, we got a lot done today.
CHAIN- Bud make us come kick-ass chain tensioners...when i first saw them i was kinda skeptical, but they work really well and get 500 points for visual appeal. yay! our back chain is tensioned!
for the front ones, we're going to go by last year's approch, bunny ears. since chain loosens up over time, if it does loosen up enoungh, we can always take the bunny off and put a bolt to tension it up more. good stuff.
BATTERY MOUNT- is almost finished. we just need to electrical tape-it so it doesn't conduct through the chassis (yikes) Props for good design by alecia! so now we can drive the robot around without strapping the battery to the side of the chassis with duct tape. haha.
LAUNCHER- built more of the platform and motor-securing device. it's almost finished so yay!
THINGS TO DO.
-mount bottom turret plate
-drilling holes to attach to chassis
- motor? directly to the plate (we already have a shaft hole and mounting screw holes. or we can put it elsewhere . sophia had a good idea. so direct drive the turret (van door hooked up to the plate) and in the middle put 2 gears, one on the shaft that is turning, and one on a potentiometer. they would have to be the same size gear...it sounds good to me...what do you thing emily?
-mount round turret plate.
-do we have the ball bearings? b/c we should attach them. we should also get another piece of aluminum to attach them to. get shaft and motor hooked up to the right place to fit
-ball feeder/storage
-posts need to go up. need to get materials for posts. EM- is there 80-20 that is 1/2" x 1/2" instead of 1 squared? that would be helpful.
-shower curtain, taught
-feeder to wheel (connection between storage and wheel. the prototype that Bud made us with the mousetrap maybe?
-MESH SIDES
-BUMPERS
-build and mount. specs are somewhere on the first site
-PVC pipe
-needs to start at 3ft and go up to 4ft, capped at the bottom
-NAME!!
ok so that's a lot to do. builders- no meeting this saturday (go to FOMF)but put your thinking caps on and get ready to rumble. these next two weeks are going to be killer.
and stress=dont do it. just say no. in the words of sophia through emily to me, we could build a robot that just moves in about 2 days, but what would we learn from that? or something like that.
so even if we cant do anything else, we can ram people. :)
but seriously, we got a lot done today.
CHAIN- Bud make us come kick-ass chain tensioners...when i first saw them i was kinda skeptical, but they work really well and get 500 points for visual appeal. yay! our back chain is tensioned!
for the front ones, we're going to go by last year's approch, bunny ears. since chain loosens up over time, if it does loosen up enoungh, we can always take the bunny off and put a bolt to tension it up more. good stuff.
BATTERY MOUNT- is almost finished. we just need to electrical tape-it so it doesn't conduct through the chassis (yikes) Props for good design by alecia! so now we can drive the robot around without strapping the battery to the side of the chassis with duct tape. haha.
LAUNCHER- built more of the platform and motor-securing device. it's almost finished so yay!
THINGS TO DO.
-mount bottom turret plate
-drilling holes to attach to chassis
- motor? directly to the plate (we already have a shaft hole and mounting screw holes. or we can put it elsewhere . sophia had a good idea. so direct drive the turret (van door hooked up to the plate) and in the middle put 2 gears, one on the shaft that is turning, and one on a potentiometer. they would have to be the same size gear...it sounds good to me...what do you thing emily?
-mount round turret plate.
-do we have the ball bearings? b/c we should attach them. we should also get another piece of aluminum to attach them to. get shaft and motor hooked up to the right place to fit
-ball feeder/storage
-posts need to go up. need to get materials for posts. EM- is there 80-20 that is 1/2" x 1/2" instead of 1 squared? that would be helpful.
-shower curtain, taught
-feeder to wheel (connection between storage and wheel. the prototype that Bud made us with the mousetrap maybe?
-MESH SIDES
-BUMPERS
-build and mount. specs are somewhere on the first site
-PVC pipe
-needs to start at 3ft and go up to 4ft, capped at the bottom
-NAME!!
ok so that's a lot to do. builders- no meeting this saturday (go to FOMF)but put your thinking caps on and get ready to rumble. these next two weeks are going to be killer.
and stress=dont do it. just say no. in the words of sophia through emily to me, we could build a robot that just moves in about 2 days, but what would we learn from that? or something like that.

Kilroy's Greatest Hits

Memoirs of today.
Disclaimer: some pics may be blurry because my camera's longer shutter options were somehow on at first.

Robot Name Link
Hey team. Here's an interesting link I found today. I don't think it helps us with choosing a robot name really, but I thought you'll get a good laugh at least:
http://cyborg.namedecoder.com/
Sara
http://cyborg.namedecoder.com/
Sara
Wednesday, February 01, 2006
A few turret questions
All in the pictures.
The biggest one that sort of concerns me (and please chime in Chris) is whether we should drive the turret directly or if we should drive it using a sprocket / chain setup. The reason why this decision isn't clear to me is because it AFFECTS PROGRAMMING. Chris, what is our plan to position sense, if any, if the the motor directly drives the turret? Or maybe we should let go of trying to do autonomous shooting and camera tracking all together?


The biggest one that sort of concerns me (and please chime in Chris) is whether we should drive the turret directly or if we should drive it using a sprocket / chain setup. The reason why this decision isn't clear to me is because it AFFECTS PROGRAMMING. Chris, what is our plan to position sense, if any, if the the motor directly drives the turret? Or maybe we should let go of trying to do autonomous shooting and camera tracking all together?

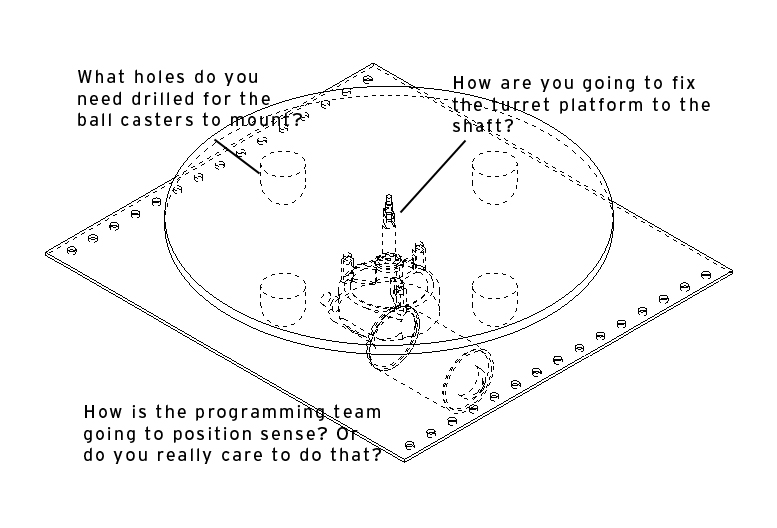
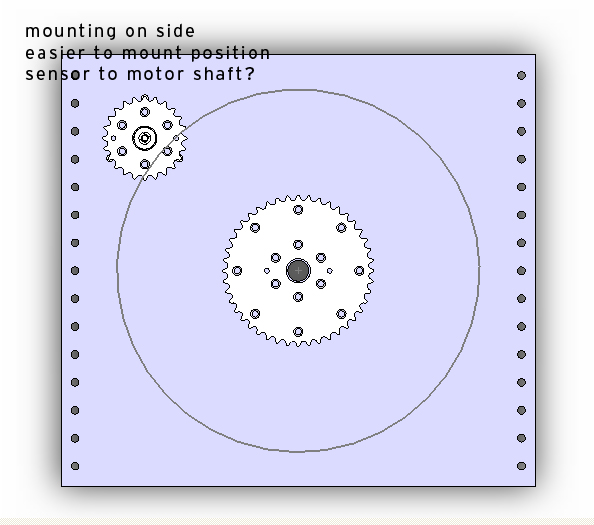
tapped holes in 80-20 so we don't have to use "L" brackets. yay!
took apart arm from last yaer, kersten designed an awesome motor mount thing so it doesn't move around.
jen and chirs and Jimmy took the aluminum plate over to ideo and drilled out a hole for the shaft. they are also drilling out holes for the side so we can attach it to the chassis.
in terms of the stainless steel plate, we cut one and a 1/2 of the sies, before the blade went out...boo-hiss.
so we still need a piece of aluminum for the turret, around 1/8 of an inch.
ok the computer just went dark so i cant really see anything, so ciao for now.
took apart arm from last yaer, kersten designed an awesome motor mount thing so it doesn't move around.
jen and chirs and Jimmy took the aluminum plate over to ideo and drilled out a hole for the shaft. they are also drilling out holes for the side so we can attach it to the chassis.
in terms of the stainless steel plate, we cut one and a 1/2 of the sies, before the blade went out...boo-hiss.
so we still need a piece of aluminum for the turret, around 1/8 of an inch.
ok the computer just went dark so i cant really see anything, so ciao for now.
Perspective
 By Saturday, FEBRUARY 5TH last year, with 17 days left, we had a completely functional arm. (How do I know, I took the photo to the left on that day, and it's marked with the date.
By THURSDAY, FEBRUARY 10TH (2005), we had a completely functional robot with 12 days left.
We will not be there this year. I am optimistic that we can possibly potential have something sort of all integrated by zero days left, but even with that I am not sure.
But that's one person's opinion,
Emily
Subscribe to:
Posts (Atom)